Project
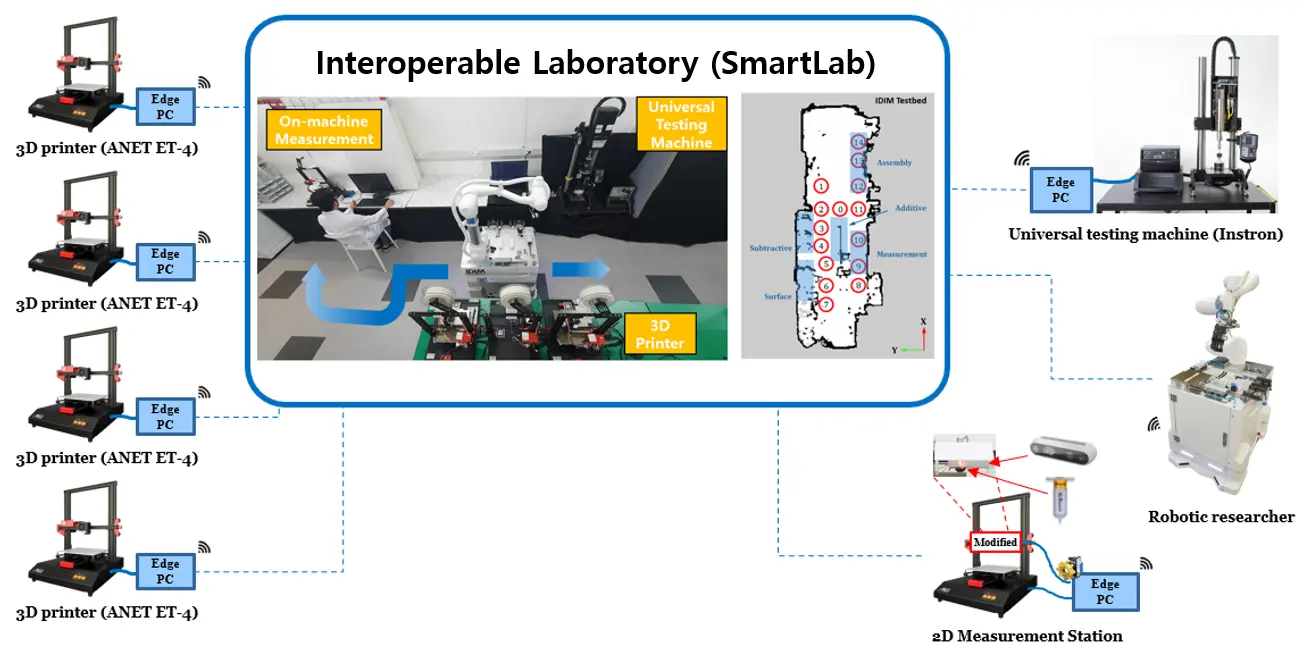
The project explored an interoperable smart laboratory in which robotic systems and experimental equipment could exchange information and execute parts of a laboratory workflow with less direct human intervention.
Modular gripper concept in operation.
My contribution
I worked on the communication layer between experimental equipment and the robot, designed a modular tool-changing gripper concept, and programmed collaborative-robot experimental scenarios.
Subsequent development
I contributed to the early development of this project during my undergraduate research internship in 2020. The project subsequently evolved into SmartLab, described in the following publication by the research team:
SmartLab: Flexible and interoperable manufacturing laboratory system for remote education and research using a mobile manipulator. Journal of Computational Design and Engineering, 2025.
My involvement was in the early development stage; I am not a co-author of this publication.
Recognition
The broader project received 1st Place in the 2020 International S.M.A.R.T Startup Competition.