Selective communication
Move only useful information through the team: who should communicate, when, and what should be exchanged.
ROBIN INHO KEE · UNIVERSITY OF MICHIGAN ROBOTICS
I am a Ph.D. student in Robotics at the University of Michigan. I build practical multi-robot autonomy that interprets mission context, communicates selectively under network constraints, and predicts consequences before action.

RESEARCH FOCUS
I study how robot teams identify useful information, communicate it selectively, and choose actions using mission context and predicted consequences.
Move only useful information through the team: who should communicate, when, and what should be exchanged.
Connect observations and mission context to the information and decisions that matter for the team.
Compare candidate actions using predicted downstream communication, task, and risk outcomes.
SELECTED WORK
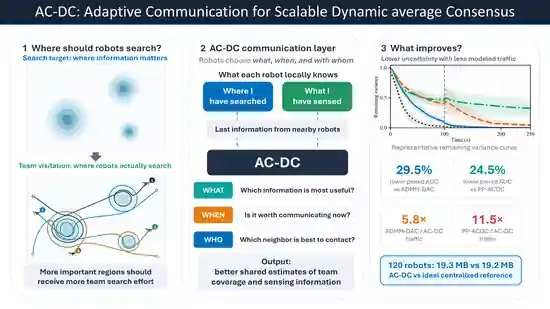
Robots jointly decide who to communicate with, when, and what state to exchange.
Project page →
Learning-based online adaptation of safety constraints with uncertainty-aware verification.
Project page →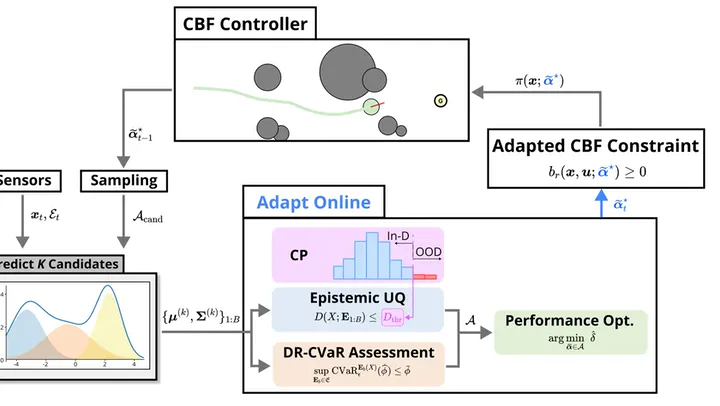
Query and validate CBF parameters online under epistemic and aleatoric uncertainty.
Project page →ABOUT
I am a Ph.D. student in Robotics at the University of Michigan, working on multi-robot autonomy, communication-aware coordination, and learning-enabled control. My research connects selective communication, mission-aware reasoning, prediction-guided action, and real robotic systems.
I am advised by Prof. Vasileios Tzoumas and Prof. Necmiye Ozay at the University of Michigan. Through the Draper Scholars Program, I am also advised by Dr. Begum Cannataro at Charles Stark Draper Laboratory. Before my Ph.D., I worked on learning-enabled safety-critical control at Michigan and on wearable assistive robots at KIST.
Outside research, I enjoy weightlifting and music.