Motivation
Control Barrier Functions can enforce safety, but their class-K parameters strongly affect controller behavior under input constraints. A parameter that is too conservative can produce deadlock or slow progress; a parameter that is too aggressive can make the safety filter infeasible and lead to a collision.
A single fixed parameter choice therefore does not work equally well across all robot states and nearby environments.
Online Adaptive ICCBF
We developed an online adaptation framework that evaluates candidate ICCBF parameters from the current robot state and local environment. Instead of committing to one parameter setting offline, the controller repeatedly asks which candidates are both reliable and useful now.
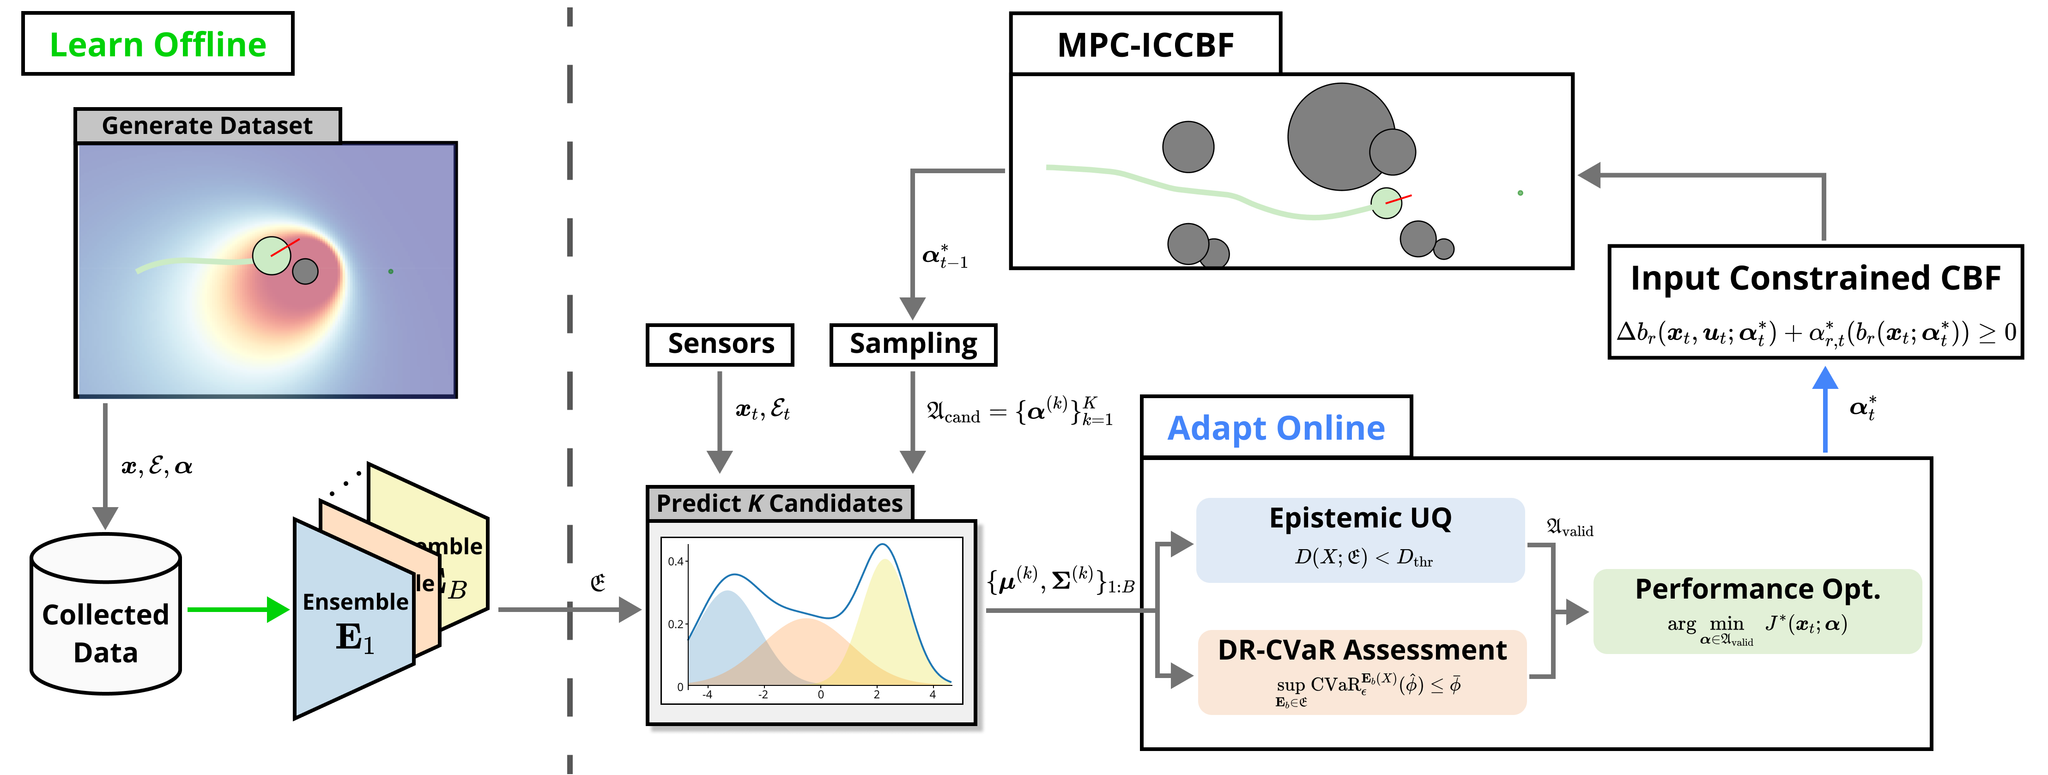
Online parameter adaptation with uncertainty-aware prediction and verification.
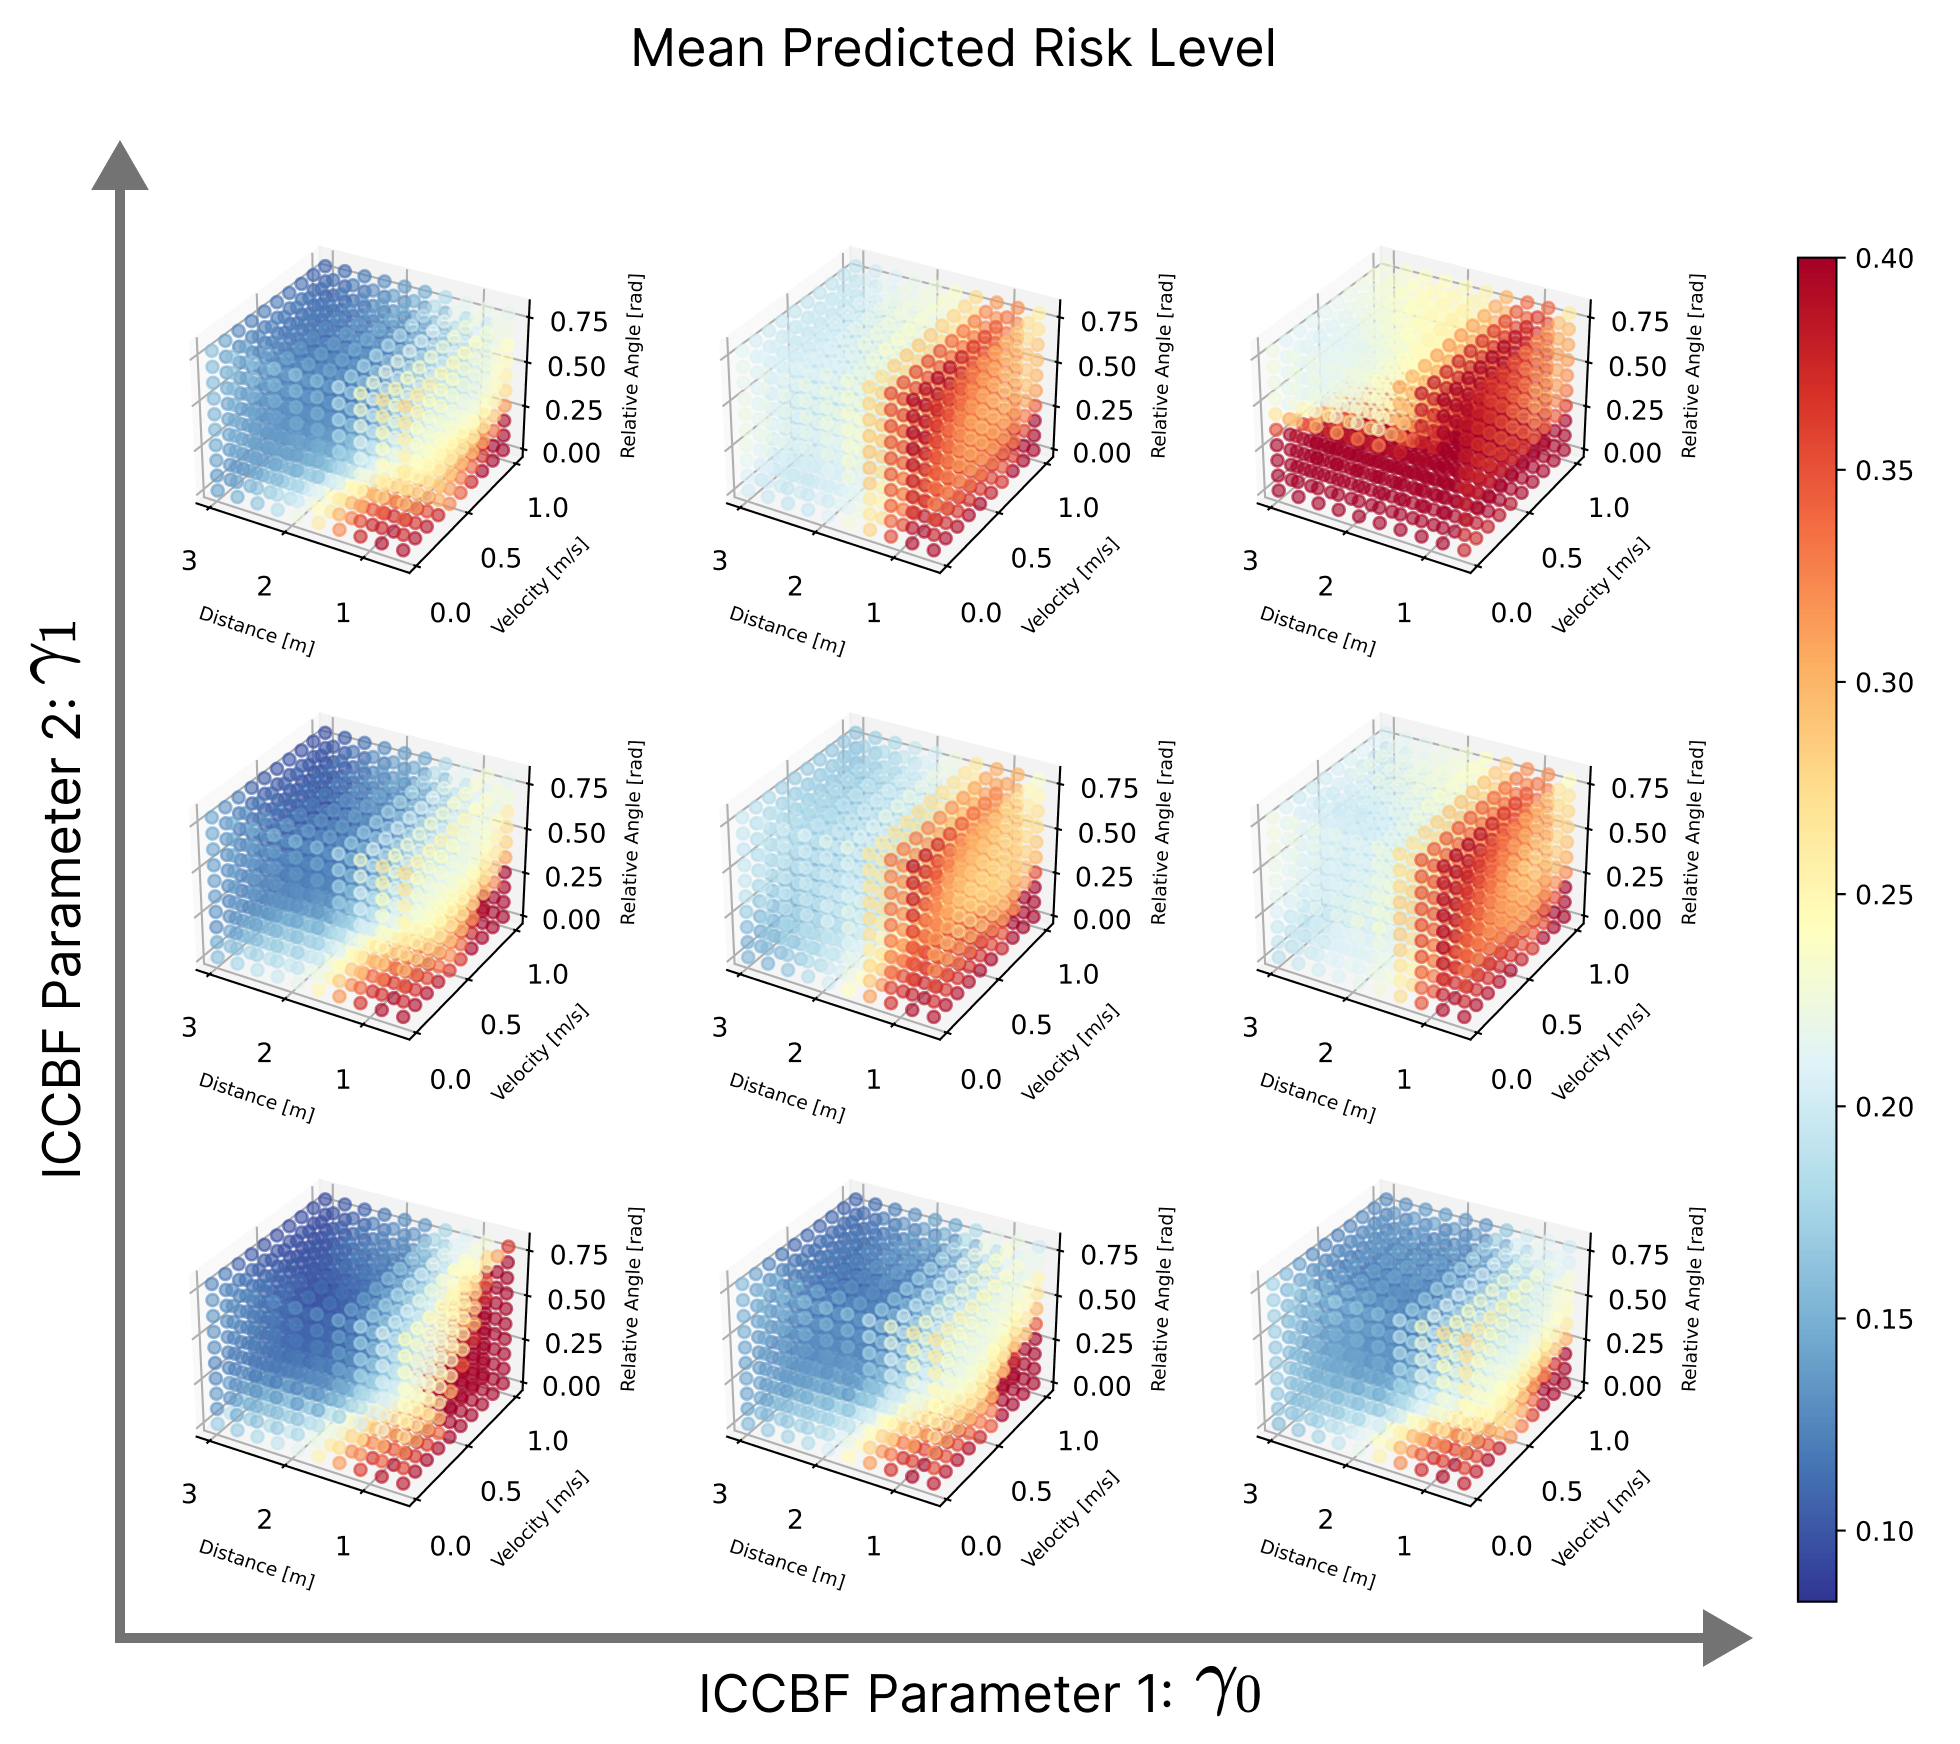
The method uses a Probabilistic Ensemble Neural Network (PENN) to predict performance and risk metrics for candidate parameters while representing both epistemic and aleatoric uncertainty.
Two-step uncertainty verification
Jensen-Rényi Divergence identifies candidate predictions with high disagreement across the probabilistic ensemble.
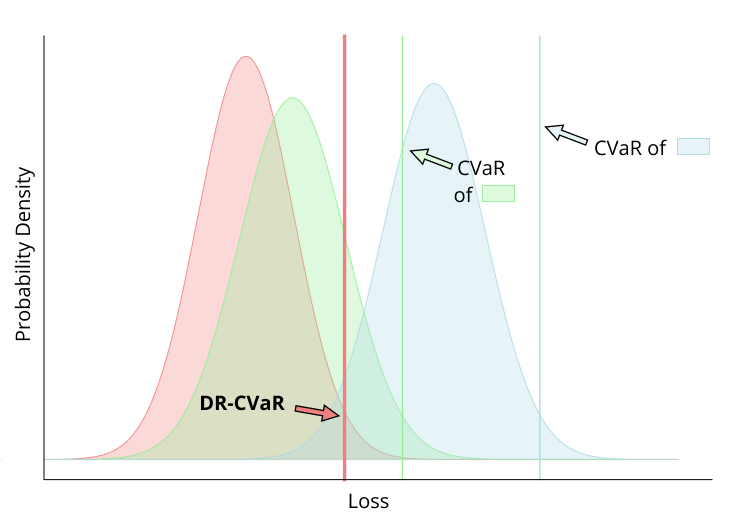
Distributionally robust CVaR screens the remaining candidates against predicted risk.
The controller selects a verified parameter using the current state and nearby environment, then updates the ICCBF-based controller.
Experiments
Online adaptation in a representative navigation trial.
A second real-time adaptation example.
We evaluated the method in robot-navigation scenarios against fixed-parameter and existing adaptive approaches. The experiments test the tradeoff the method is designed around: maintaining feasibility and safety near obstacles without forcing the robot to remain unnecessarily conservative when more aggressive parameters are locally appropriate.
Takeaway
The project turns CBF parameter selection from a one-time tuning problem into an online, uncertainty-aware decision. The controller adapts its safety parameters to the current state and environment while restricting updates to candidates that pass the verification pipeline.
My contribution
I developed and implemented the probabilistic ensemble model for real-time ICCBF adaptation, integrated the uncertainty-verification pipeline, and contributed to the simulation and robot-navigation experiments.