How should robot teams understand what matters, share it selectively, and act using predicted consequences?
CURRENT RESEARCH
Selective communication for scalable multi-robot coordination
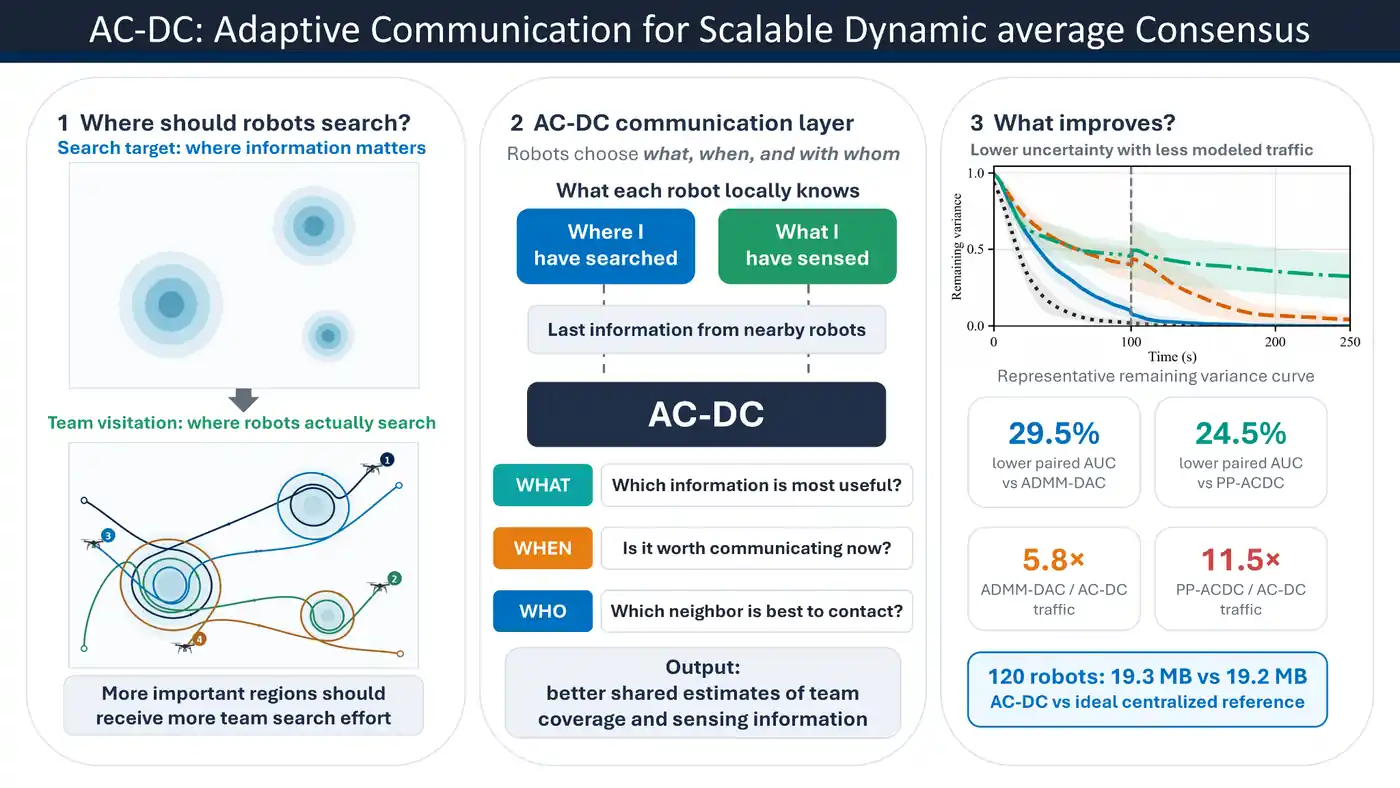
AC-DC: Adaptive Communication for Scalable Dynamic Average Consensus
Adaptive peer-to-peer communication for multi-robot ergodic search under finite range, finite rate, and receiver-side interference.
SELECTED RESEARCH