Goal
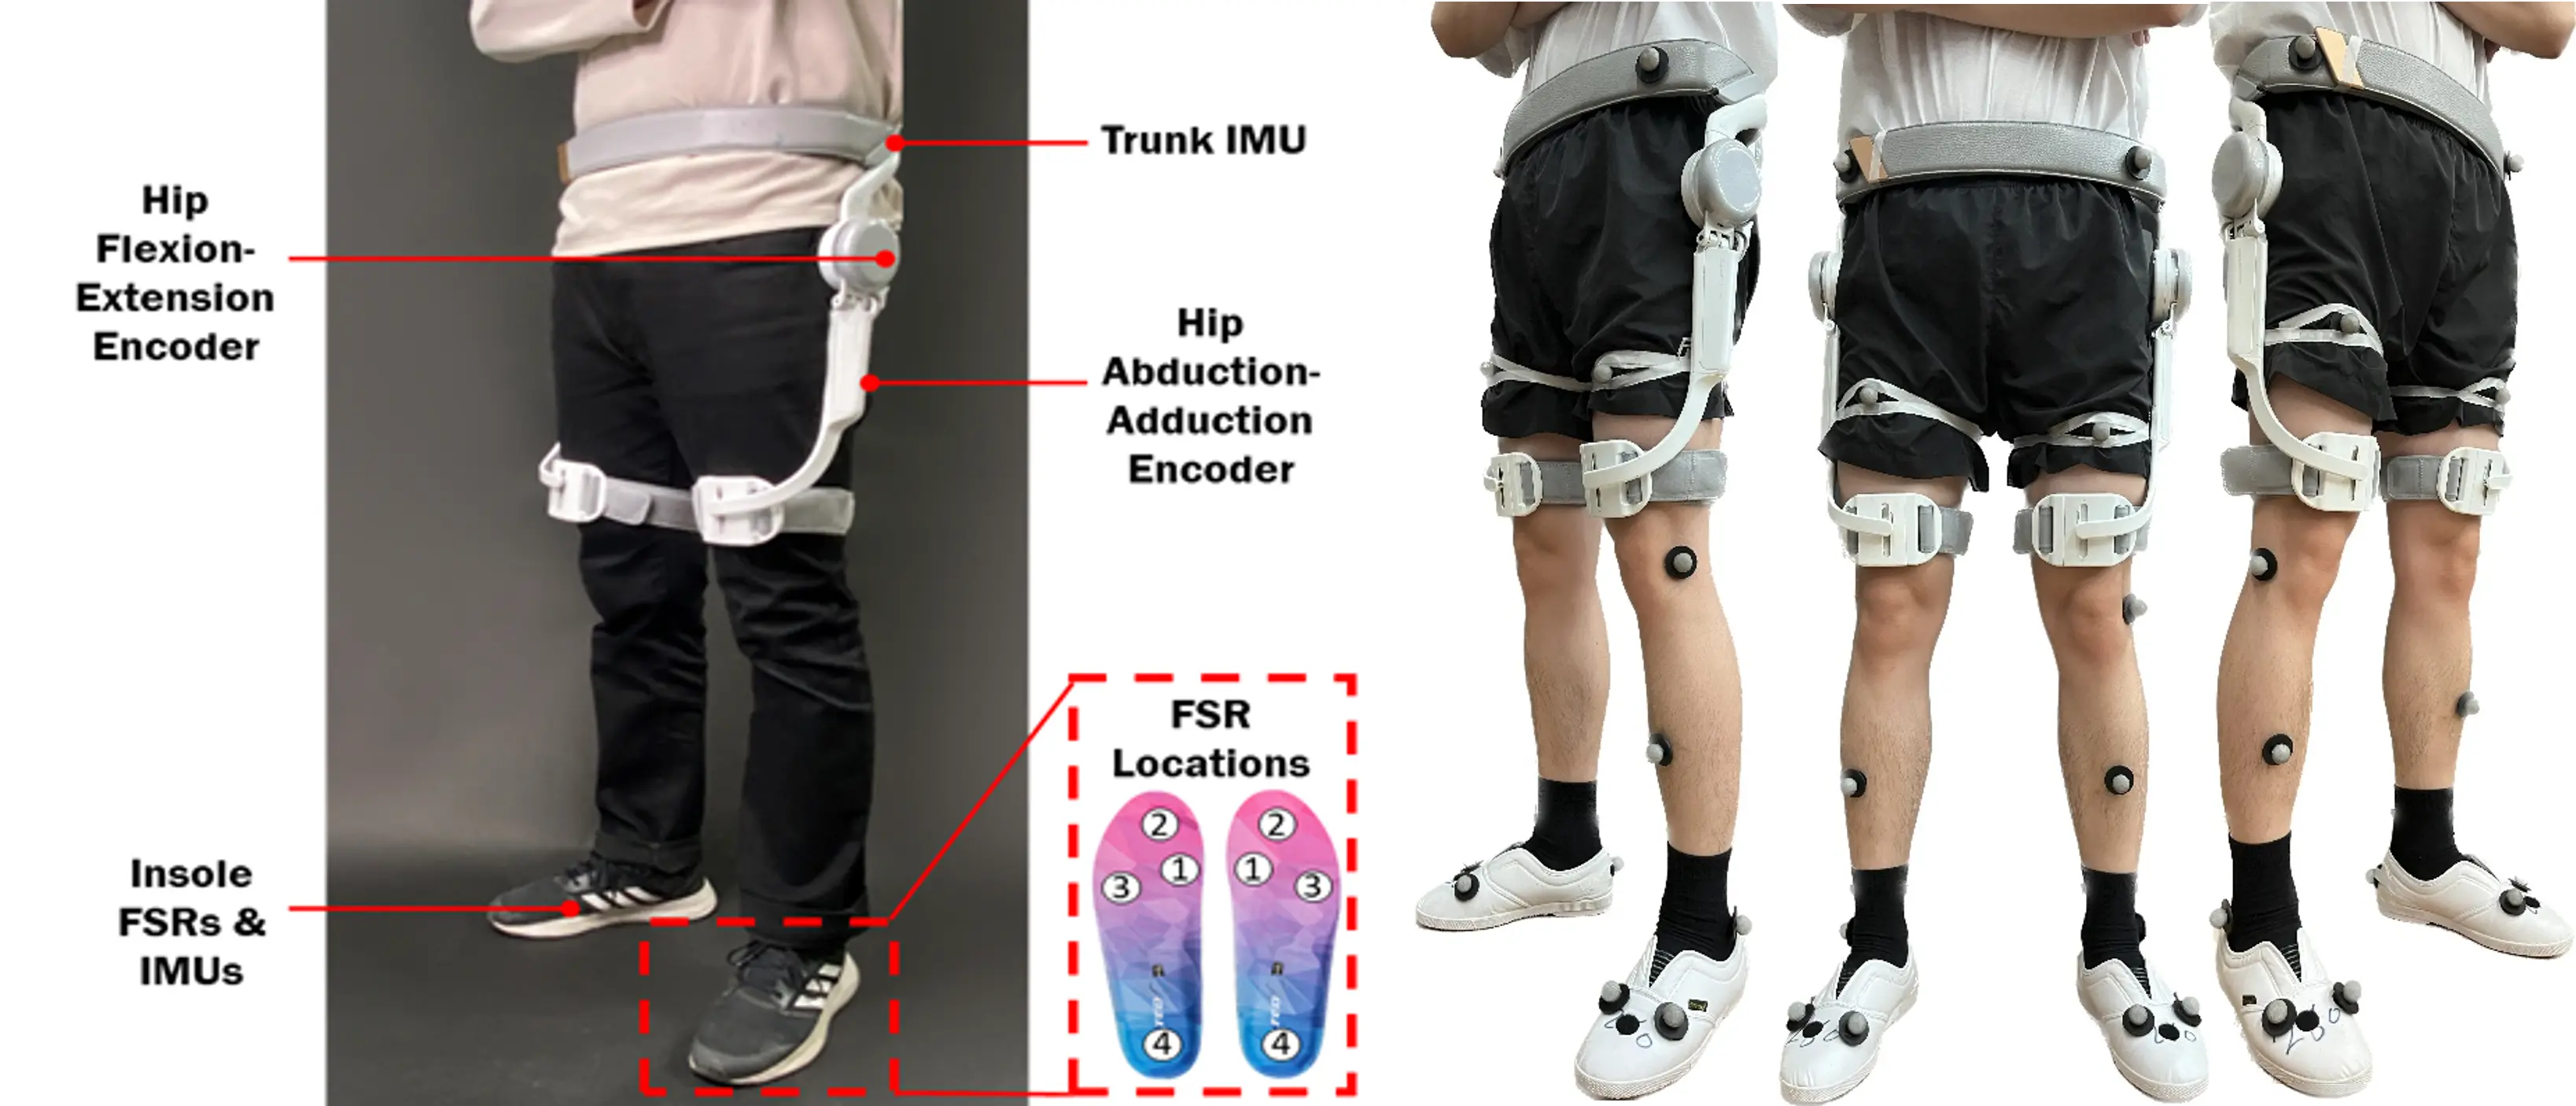
Daily assistive robots can do more than provide torque assistance: their onboard sensing can also reveal how a person is walking. At KIST, I worked on estimating gait trajectories and clinically relevant gait parameters from wearable-robot and insole sensors.
Learning-based gait estimation
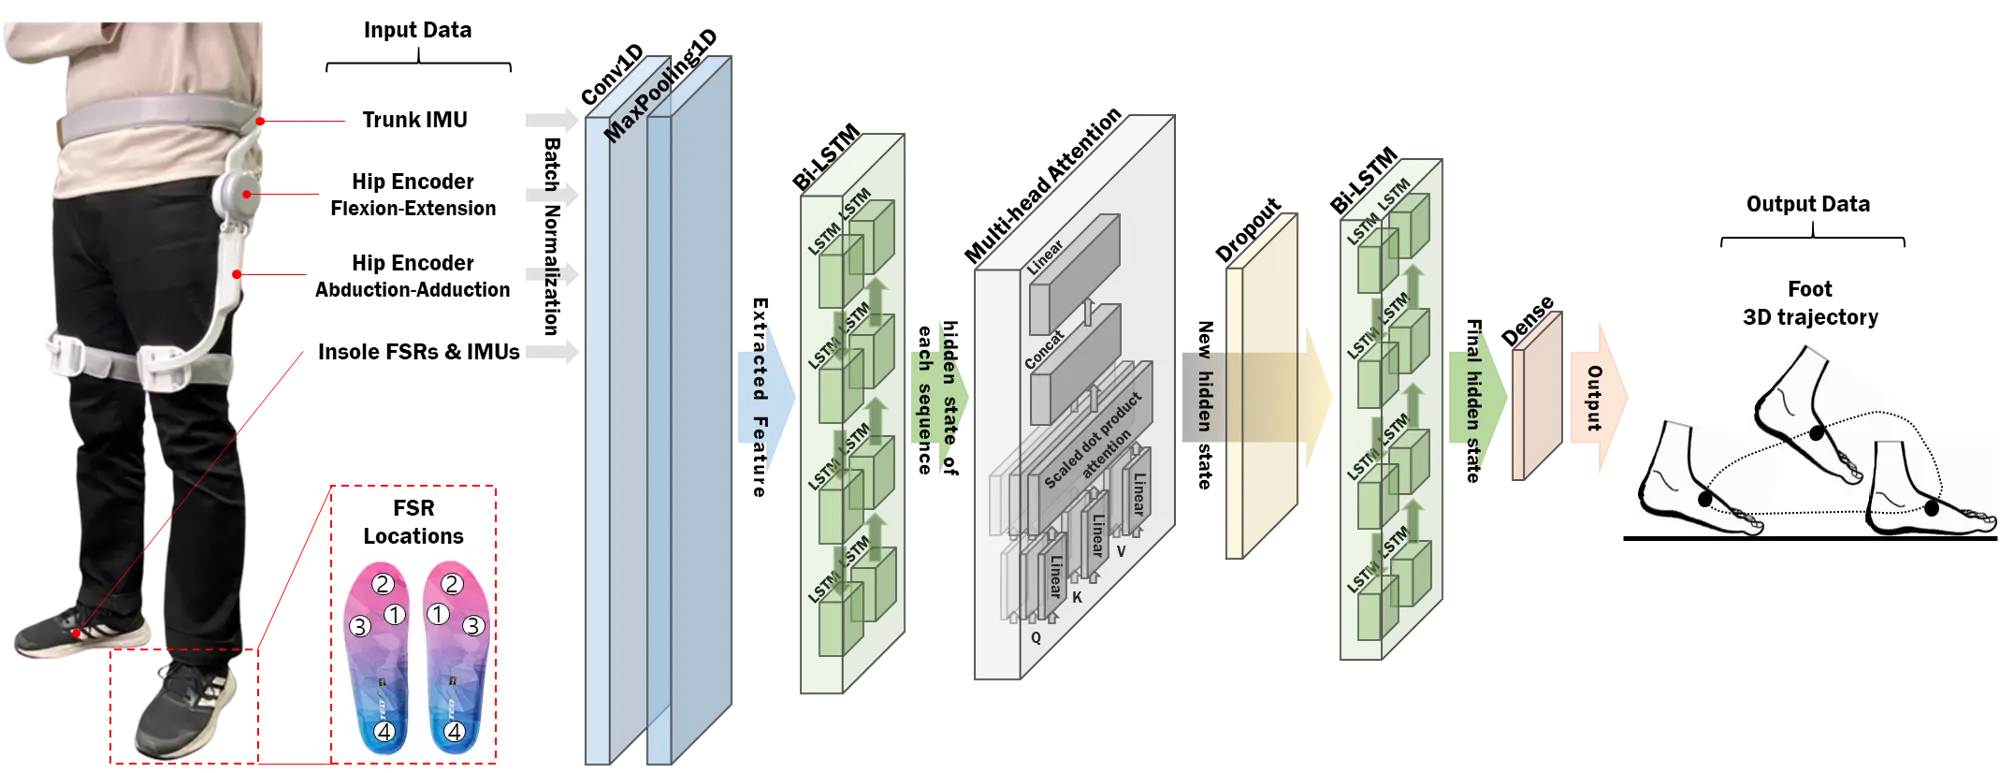
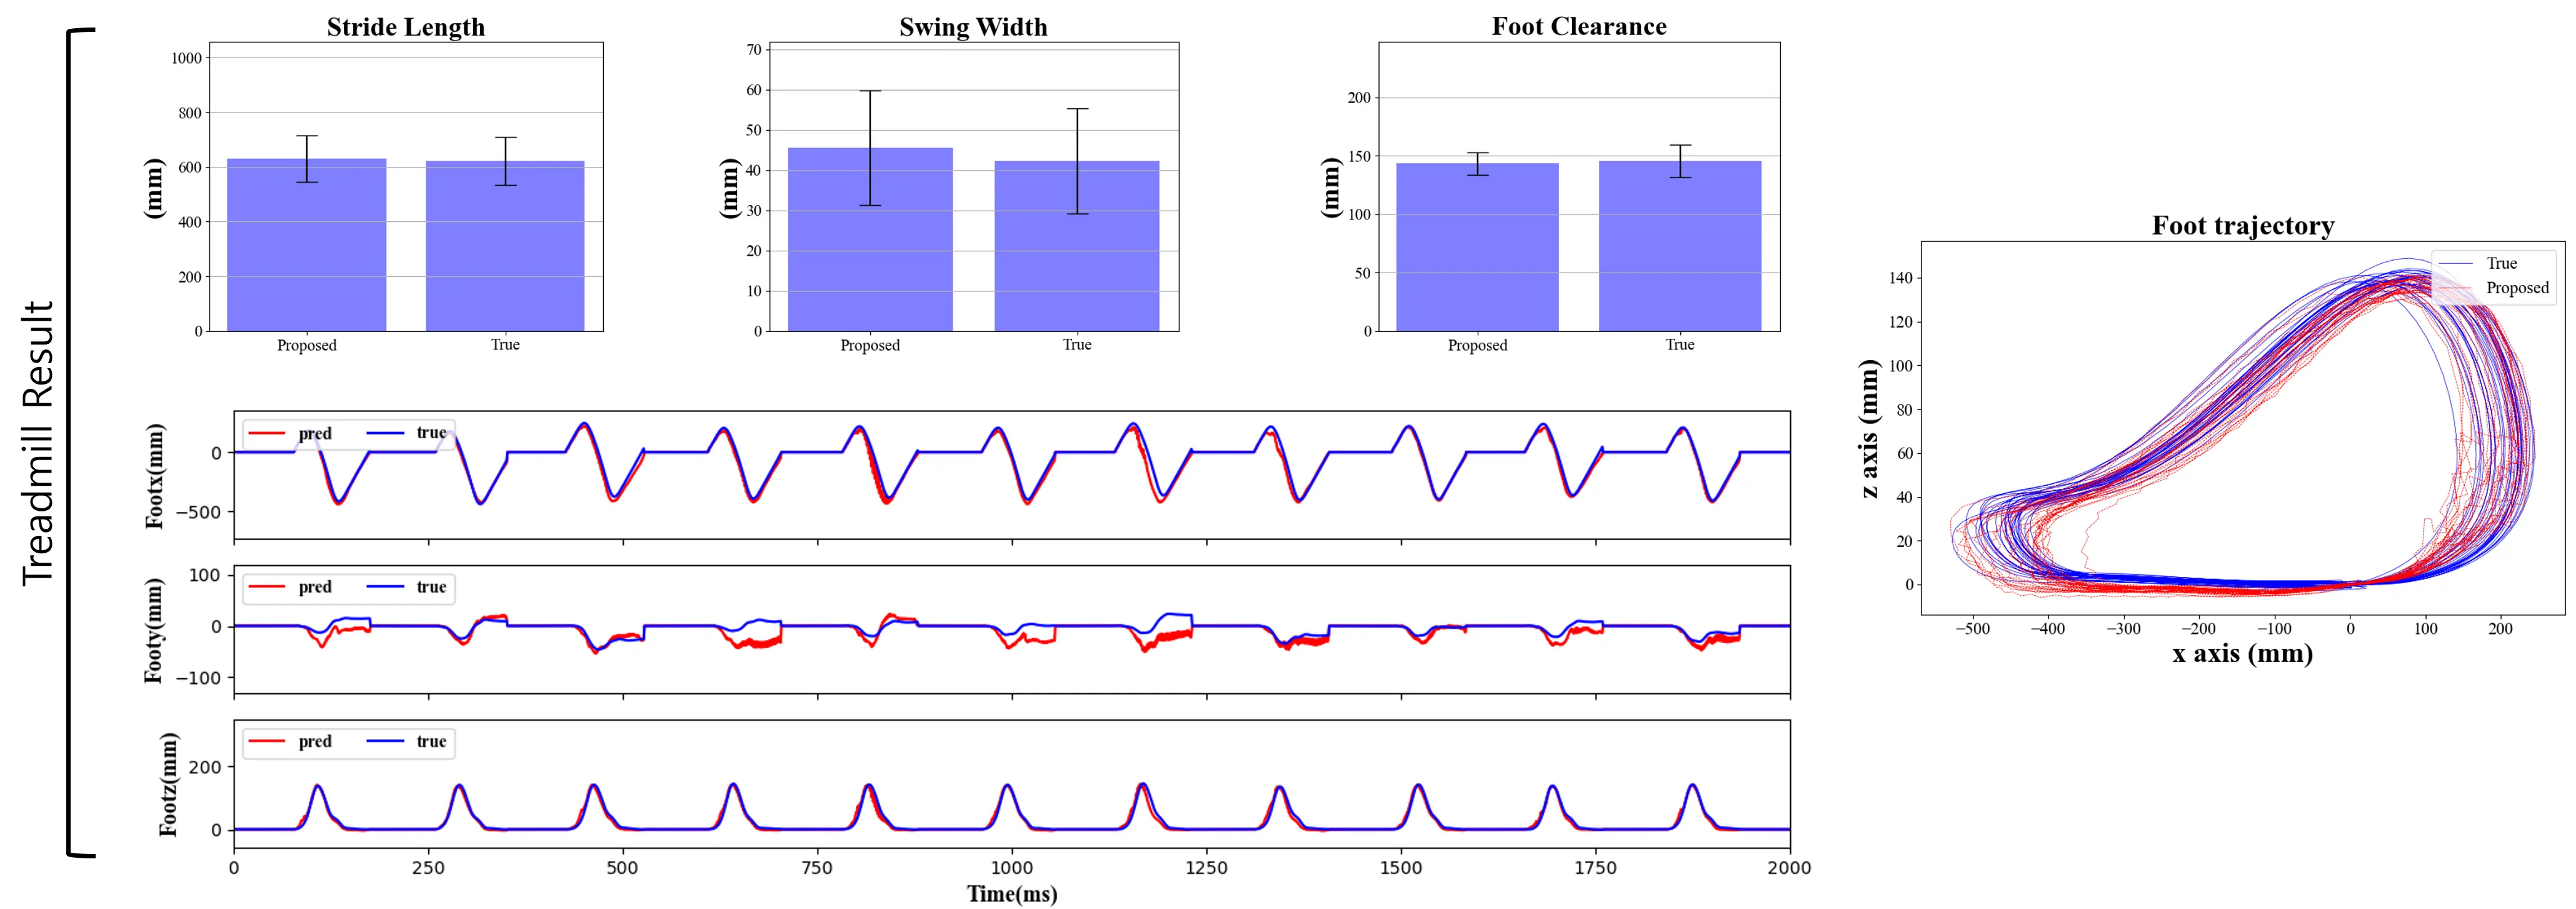
I developed deep-learning models that fuse robot and wearable sensing to estimate foot trajectories and gait parameters for treadmill and overground walking.
Experiments
I helped run motion-capture experiments with healthy participants and sarcopenia patients, including treadmill, overground, and outdoor data collection.
Overground gait experiment.
Outdoor / sidewalk gait collection.
Sit-to-stand experiment with the wearable robot.
Publication direction
This work contributed to later research on daily-life sarcopenia identification using real-time gait assessment with a wearable hip assistive robot.