Problem
Spacecraft rendezvous and docking must satisfy line-of-sight, thrust, and approach constraints while still converging efficiently to the target. A Time Shift Governor (TSG) can enforce these constraints by modifying the commanded reference trajectory, but repeatedly computing the appropriate time shift can be expensive.
Approach
We developed a learning-accelerated Time Shift Governor for rendezvous and docking in both low-Earth and elliptical orbits. An LSTM predicts the time-shift parameter from recent Chief and Deputy spacecraft states, while the TSG remains responsible for constraint enforcement.
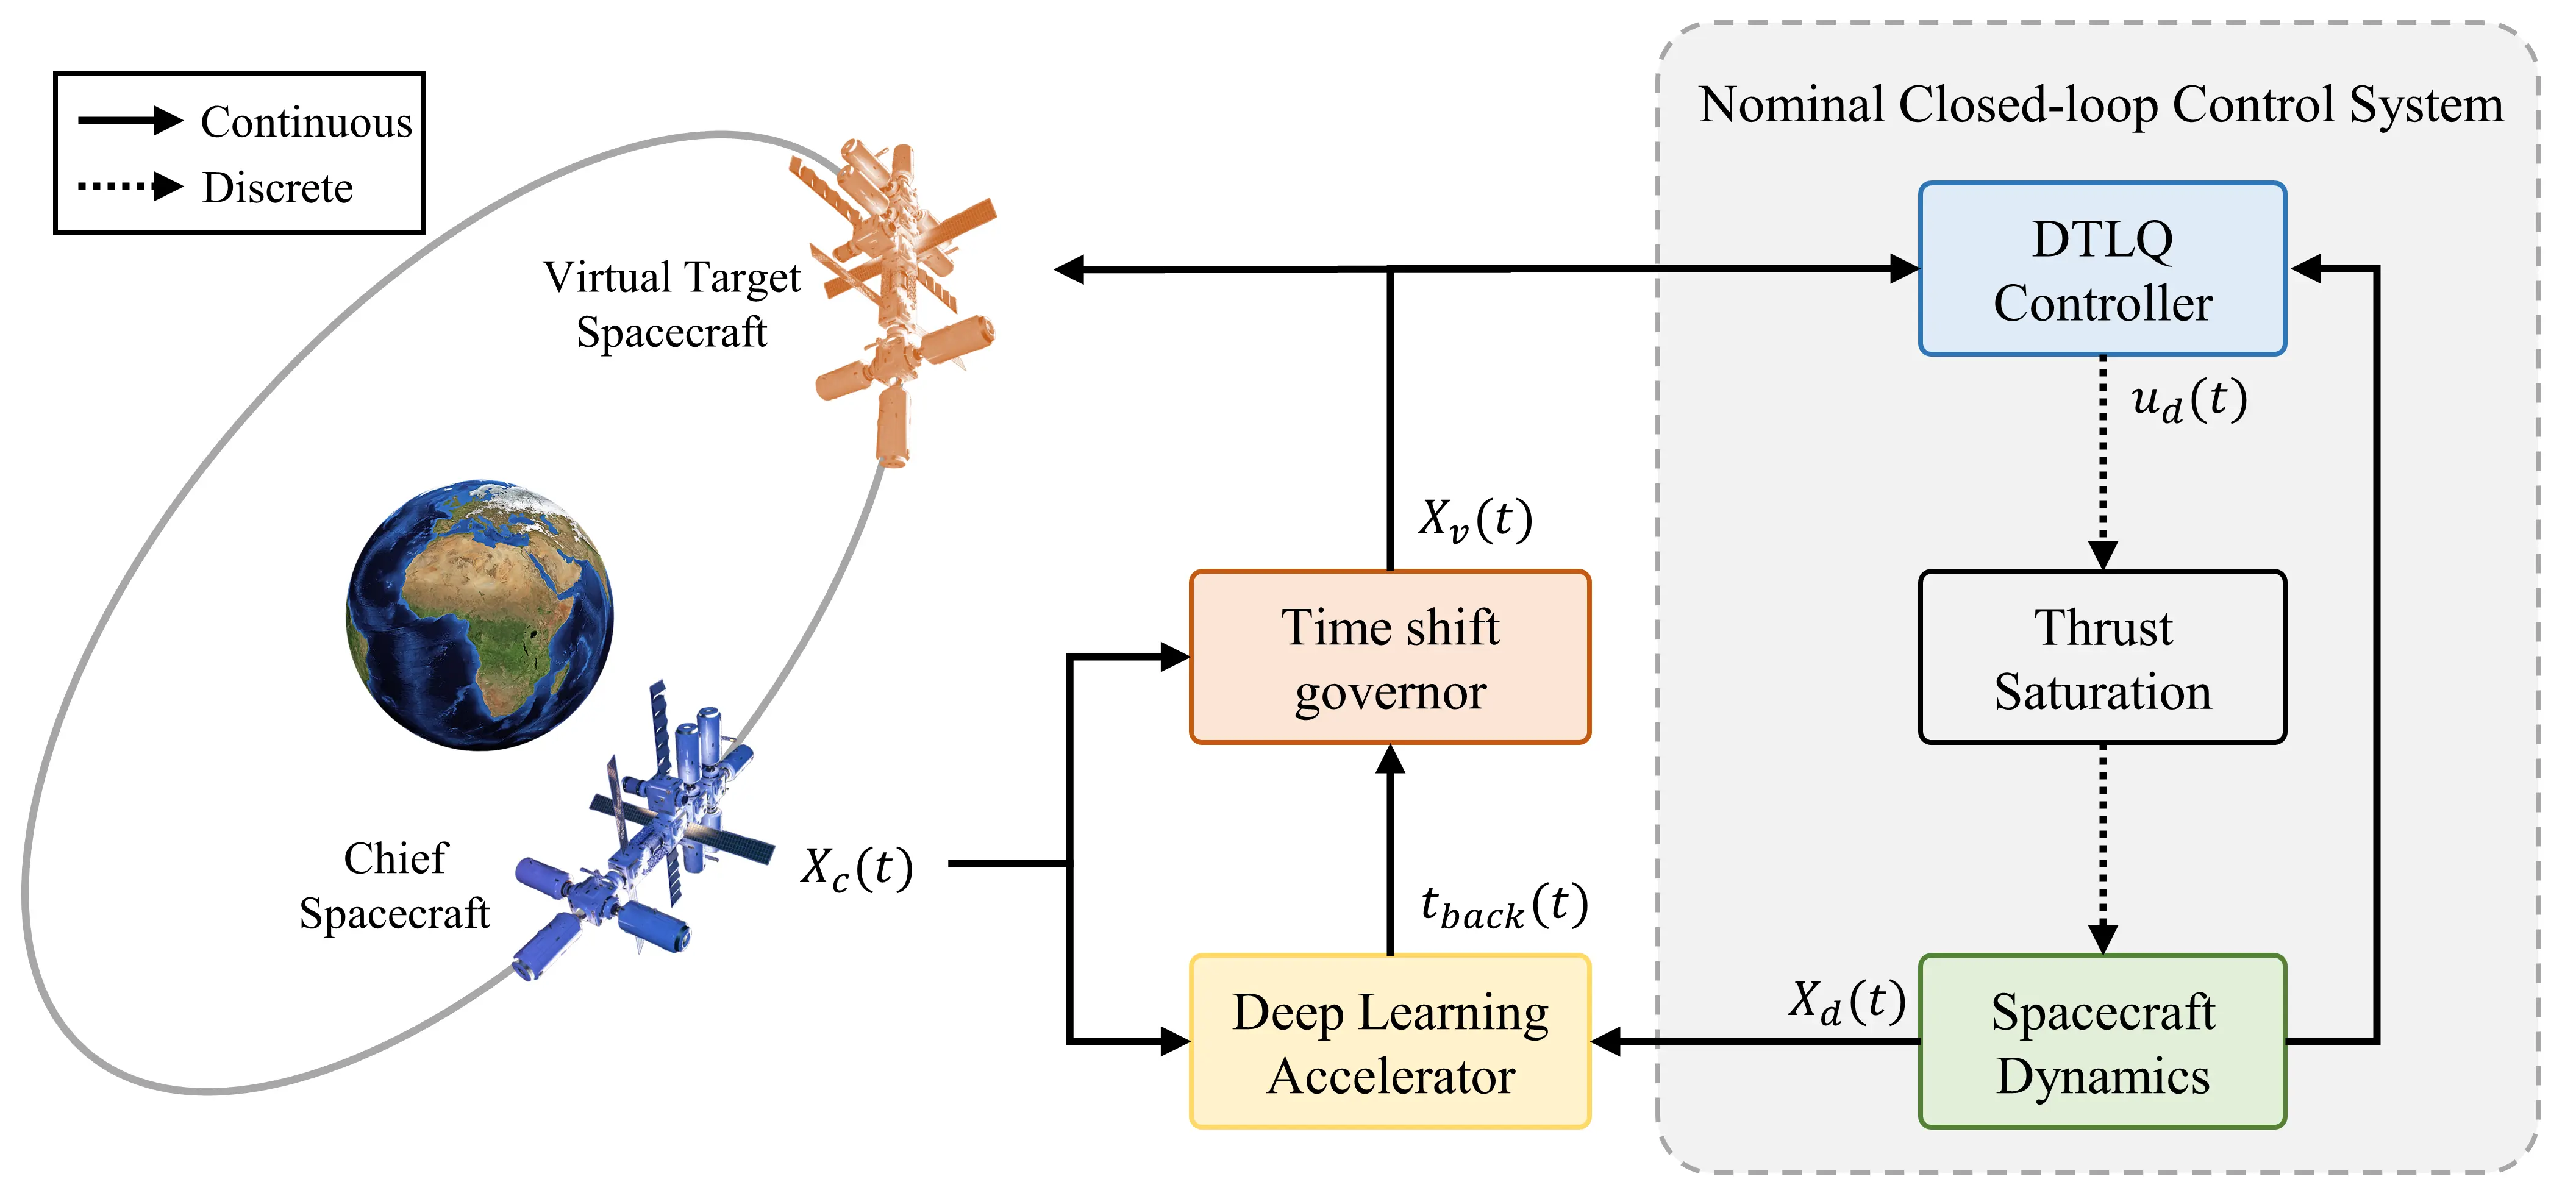
Learning-assisted Time Shift Governor for constrained spacecraft rendezvous.
Results
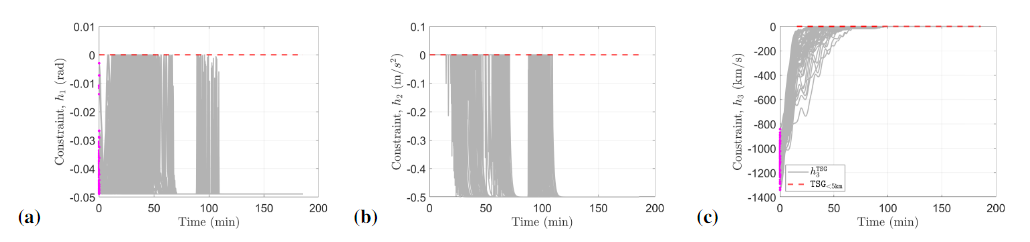
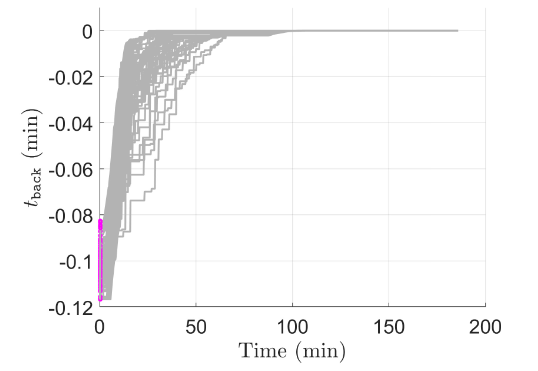
The learned predictor reduced the time required to obtain the time-shift parameter in most evaluated scenarios while the closed-loop system completed rendezvous missions under the imposed constraints.
My contribution
I co-developed the learning-based TSG formulation, including a phase-adaptive sliding window and a constraint-specific training objective, and contributed to the simulation study for rendezvous missions in LEO and elliptical orbit.