Building robots before research papers
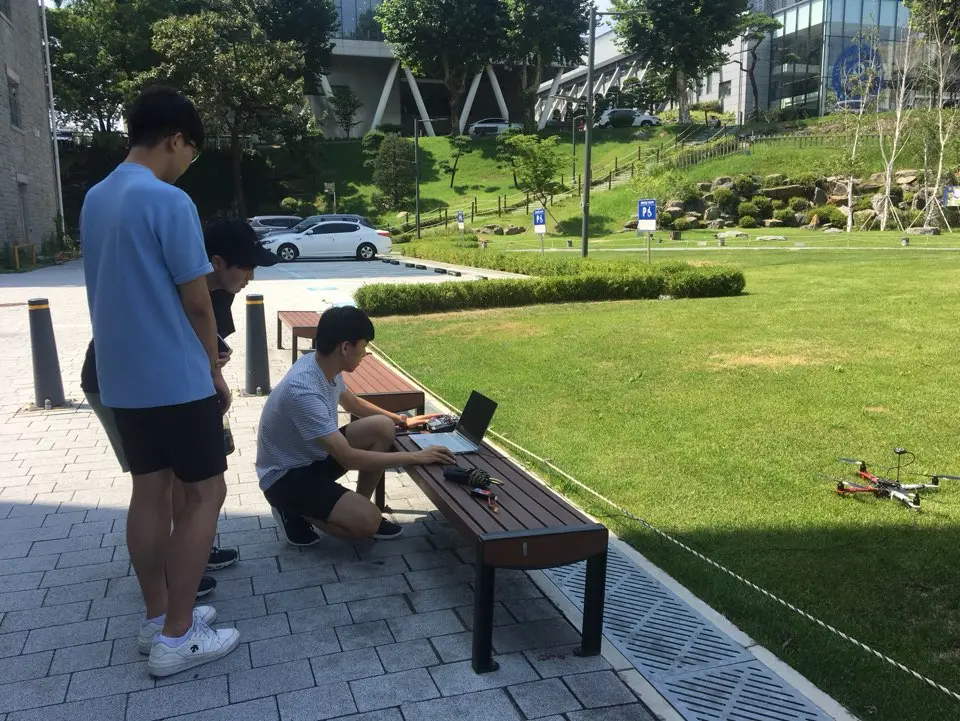
Roboin was where I learned to build complete robotic systems from hardware upward. I worked on several small platforms spanning sensing, embedded control, aerial robotics, line following, and balancing.
Early camera / CCTV robotics project.
Quadrotor project in flight.
Embedded mobile-robot project.
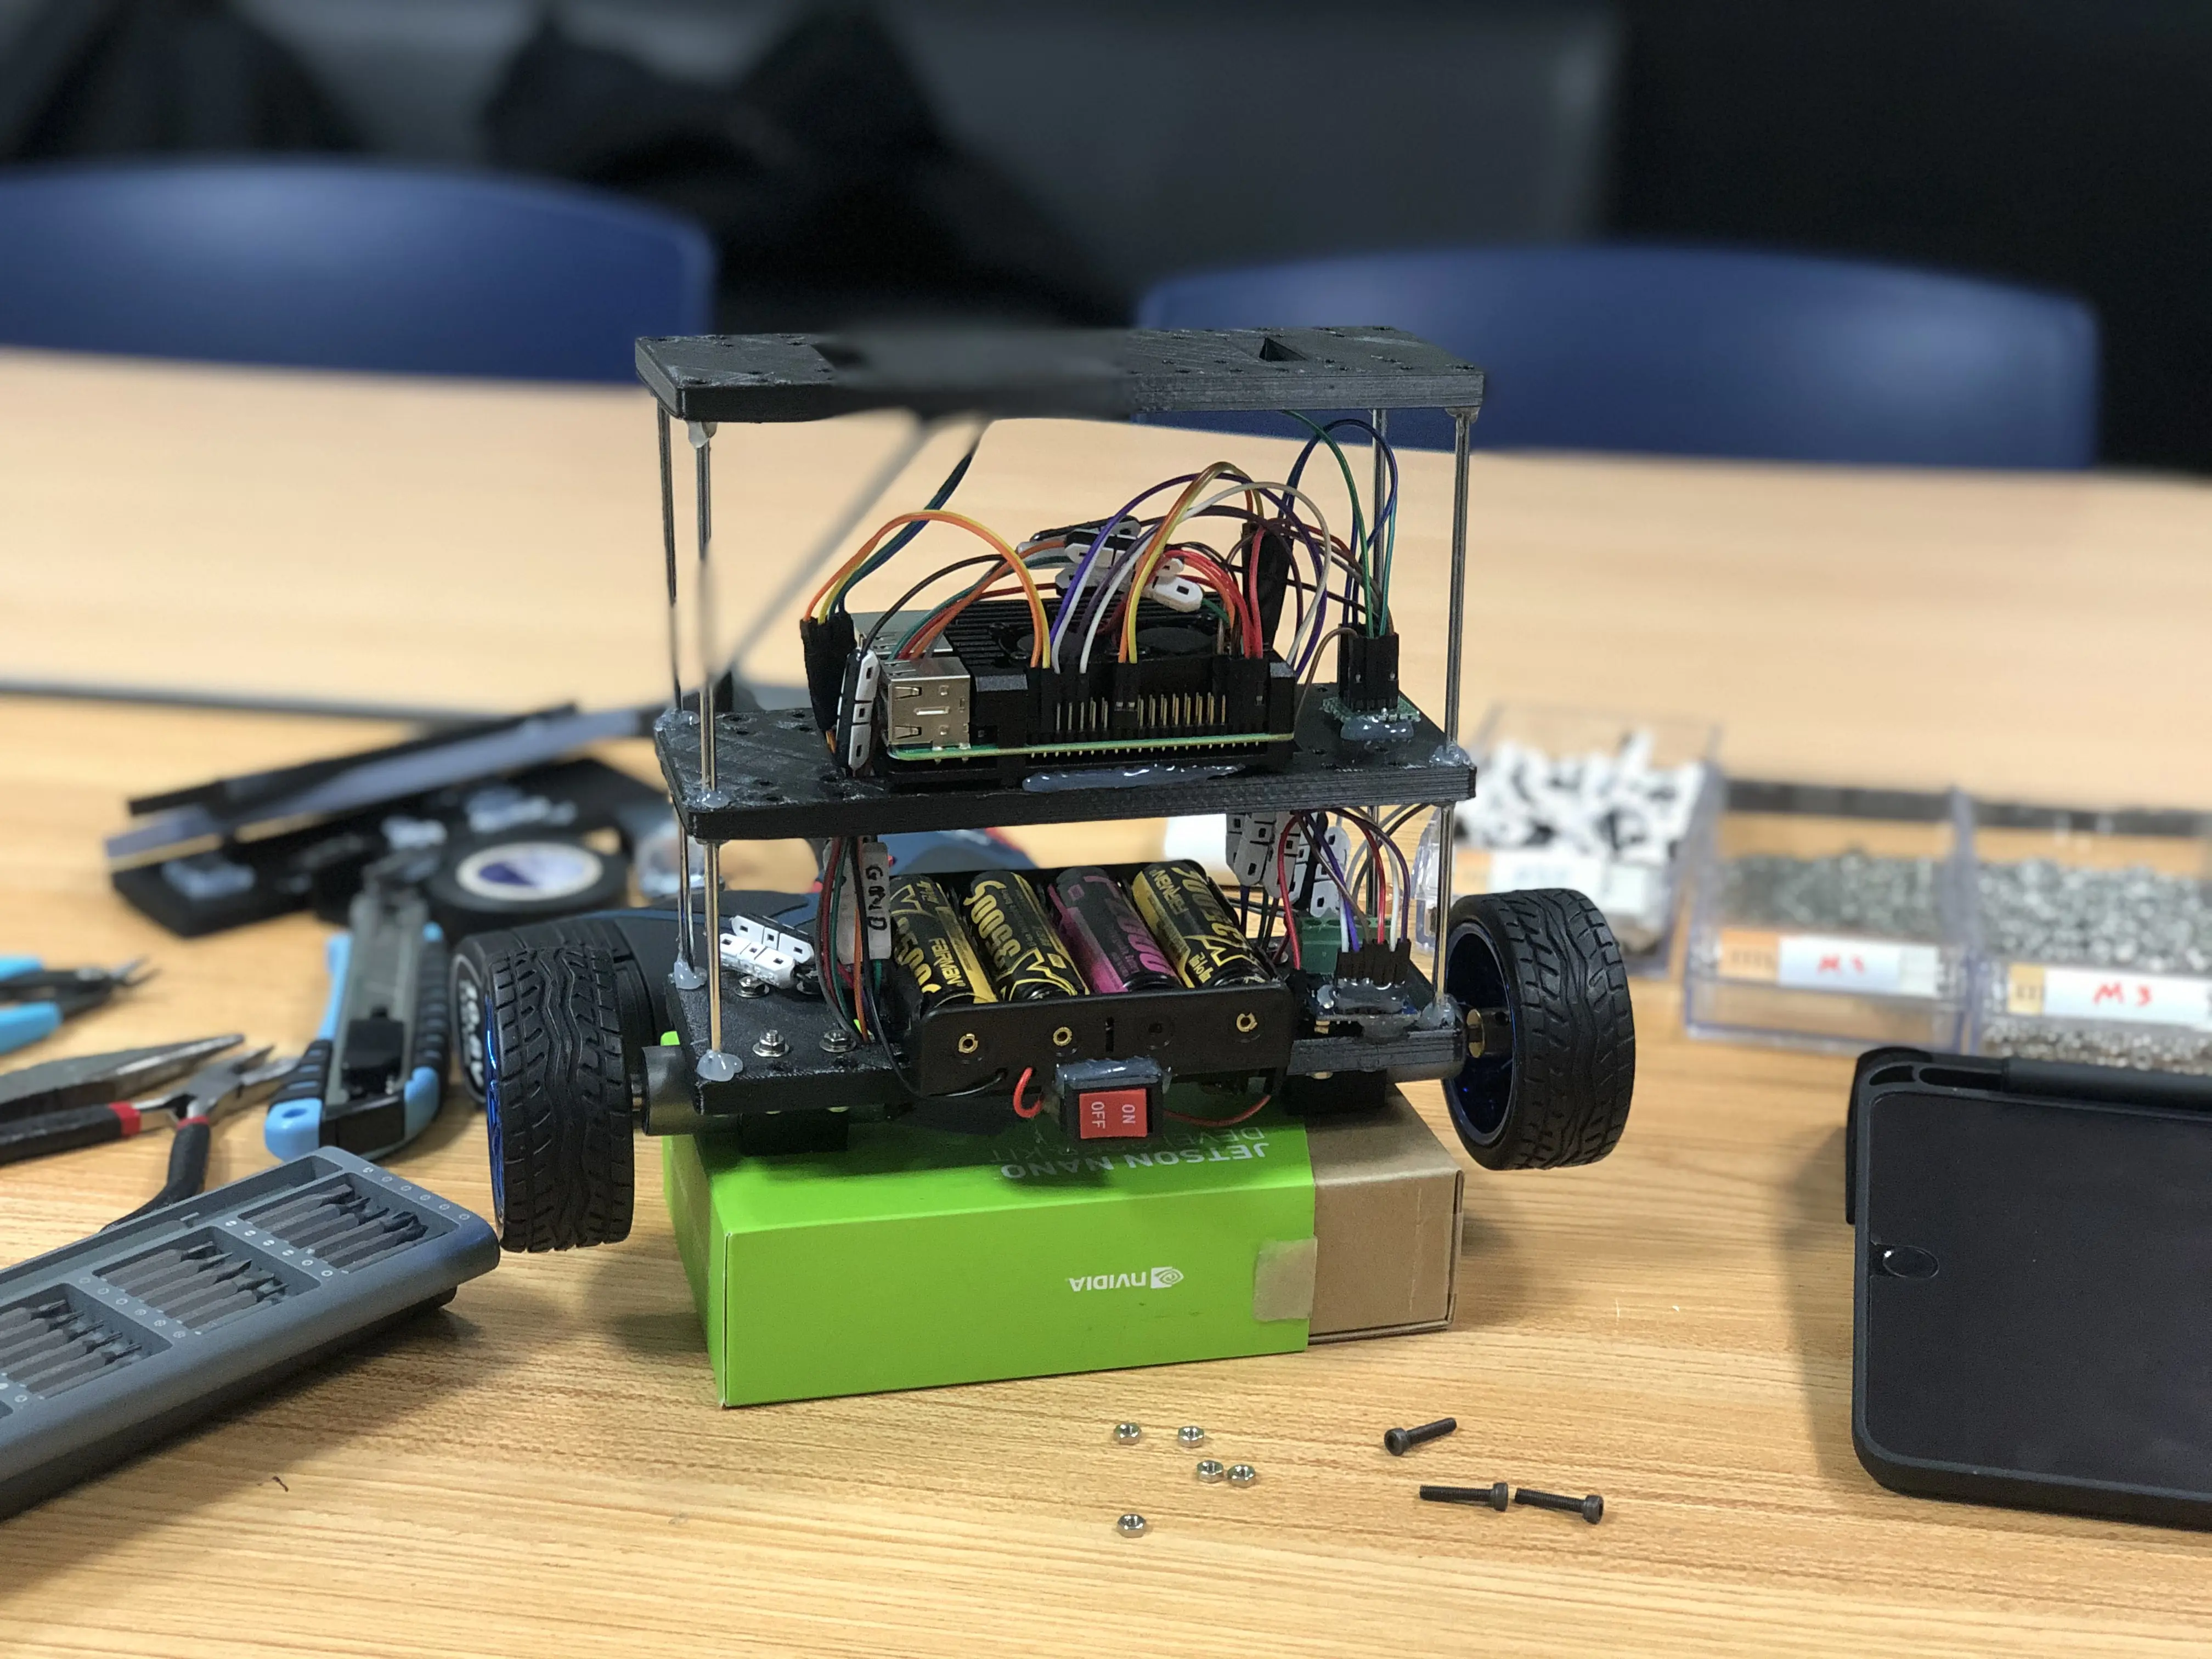
Self-balancing robot in development.
What stayed with me
These projects gave me practical experience with fabrication, embedded sensing, debugging, and integration—the physical side of robotics that continues to shape how I approach research systems today.