Project
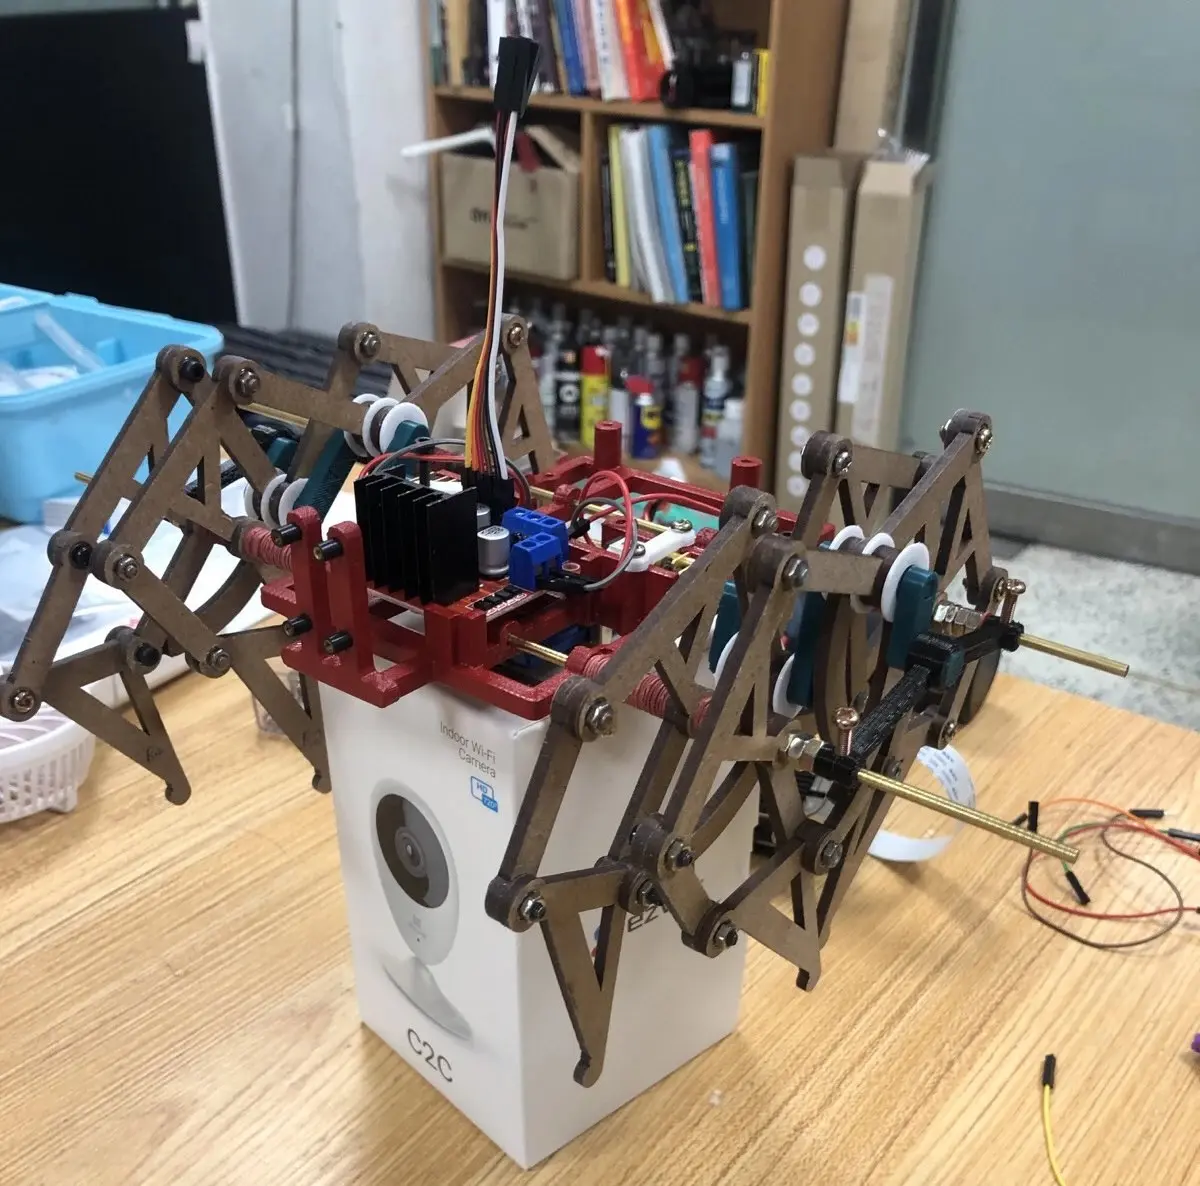
We designed and fabricated a robot based on a Theo Jansen linkage and combined it with camera-based path recognition for autonomous navigation.
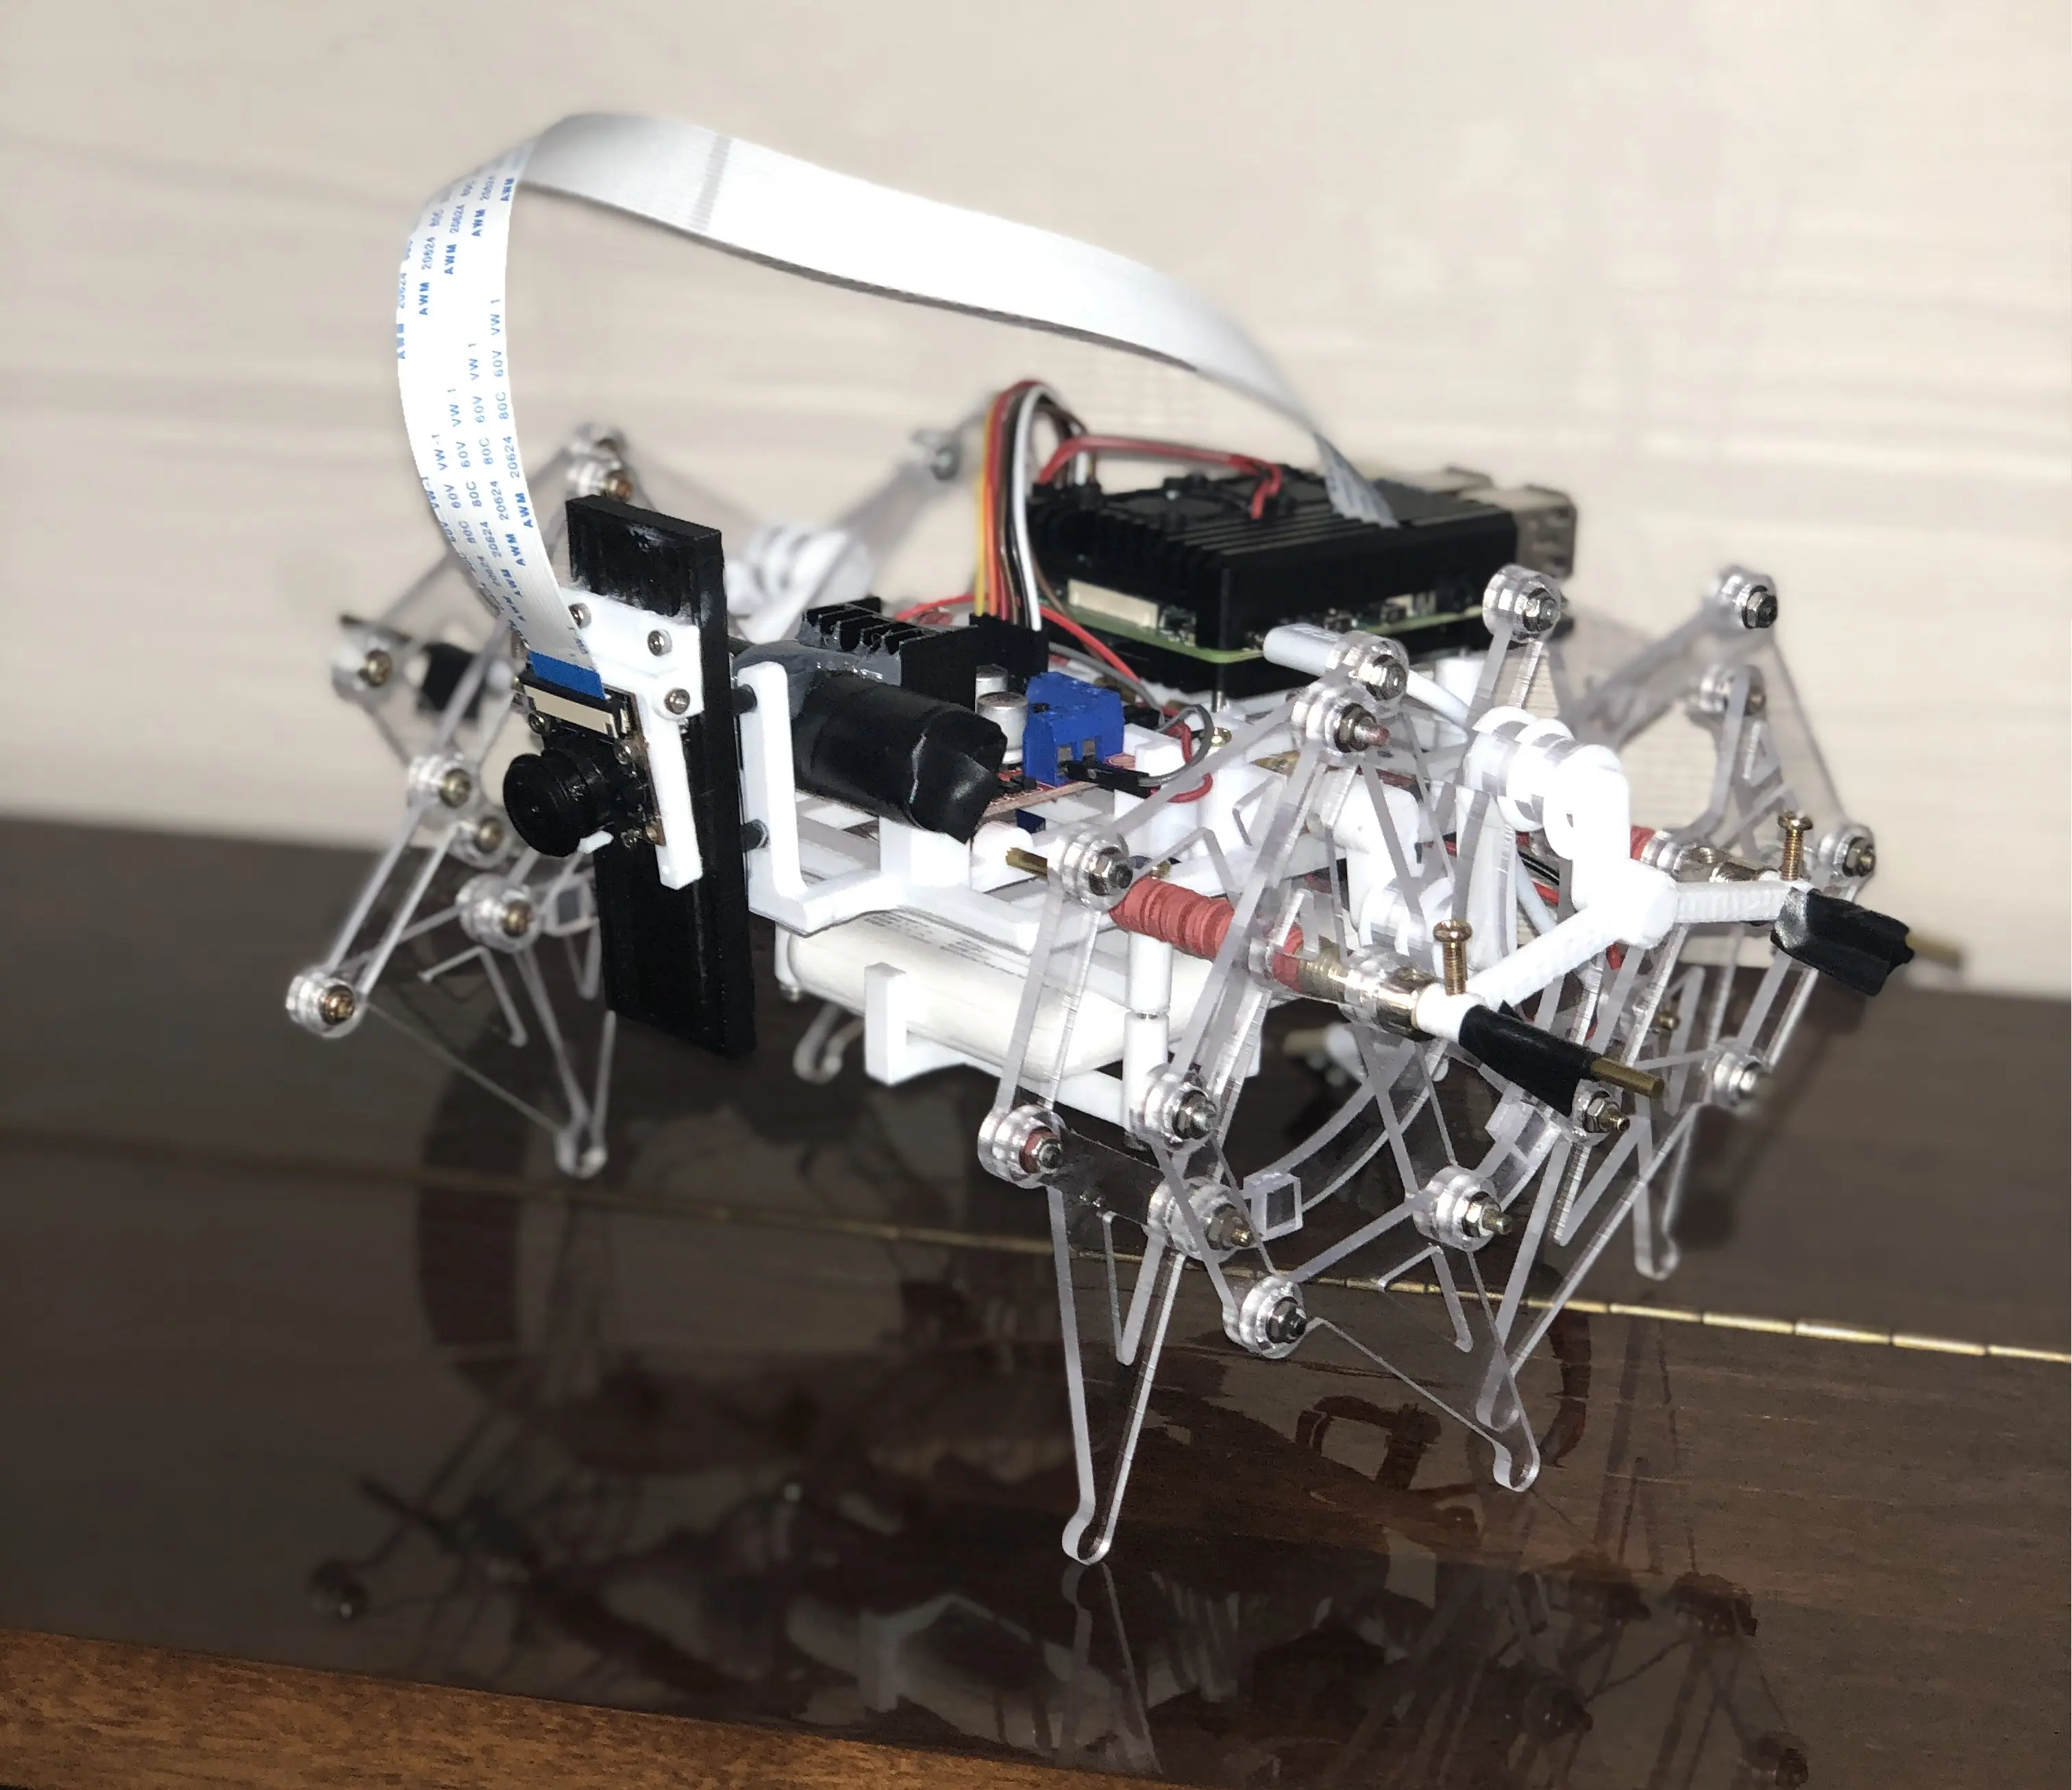
Computer-vision and mechanism test.
Autonomous navigation on the competition course.
Autonomy
A Raspberry Pi camera was used for path recognition as well as STOP-sign and AR-marker detection, allowing the robot to choose turns and execute simple commands along a course.
My contribution
I worked on hardware design and fabrication and developed the vision algorithms for path following, sign recognition, and AR-marker recognition.
Recognition
The robot recorded 1st Place in fastest completion time in the 2020 Computational Design Competition.