Why communication is part of the search problem
We study robot teams that gather information while they move. The mission priority specifies where reducing uncertainty matters most, while team visitation describes where the robots actually search. Coordinated ergodic search therefore depends on shared information about both where the team has searched and what the team has sensed.
The network is not an unlimited background service: communication has finite range and data rate, and nearby transmissions can interfere. We keep the receding-horizon ergodic controller fixed and instead adapt the communication policy that supplies its distributed information.
Two moving team quantities
Each robot tracks two dynamic team averages:
Summarize where the team has searched and provide the team-visitation estimate used by the ergodic controller.
Aggregates regional sensing information used to update uncertainty and construct the current search target together with mission priority.
Each robot controls its motion using local estimates of these two team averages rather than exact centralized team information.
AC-DC initializes each consensus state from the corresponding local input. On first successful contact for a stream, a robot pair initializes neighbor memory by exchanging the complete stream. Later communication decisions use local input changes, stored neighbor blocks, and compact drift summaries; a summary helps score an exchange but does not itself update the consensus state.
What AC-DC adapts
Before receiving a neighbor’s current block, each robot decides:
Select the consensus-state block whose exchange is predicted to be most useful.
Request communication when the exchange score is high enough, with an age-based refresh fallback when no score-qualified neighbor exists.
Among qualified neighbors, request the neighbor with the largest score for the selected block.
The selected exchange still has to be schedulable and successfully delivered under the radio model. When both directions of an ordinary pairwise exchange succeed, the robots average the exchanged block and refresh their stored neighbor information.
Dynamic-priority search
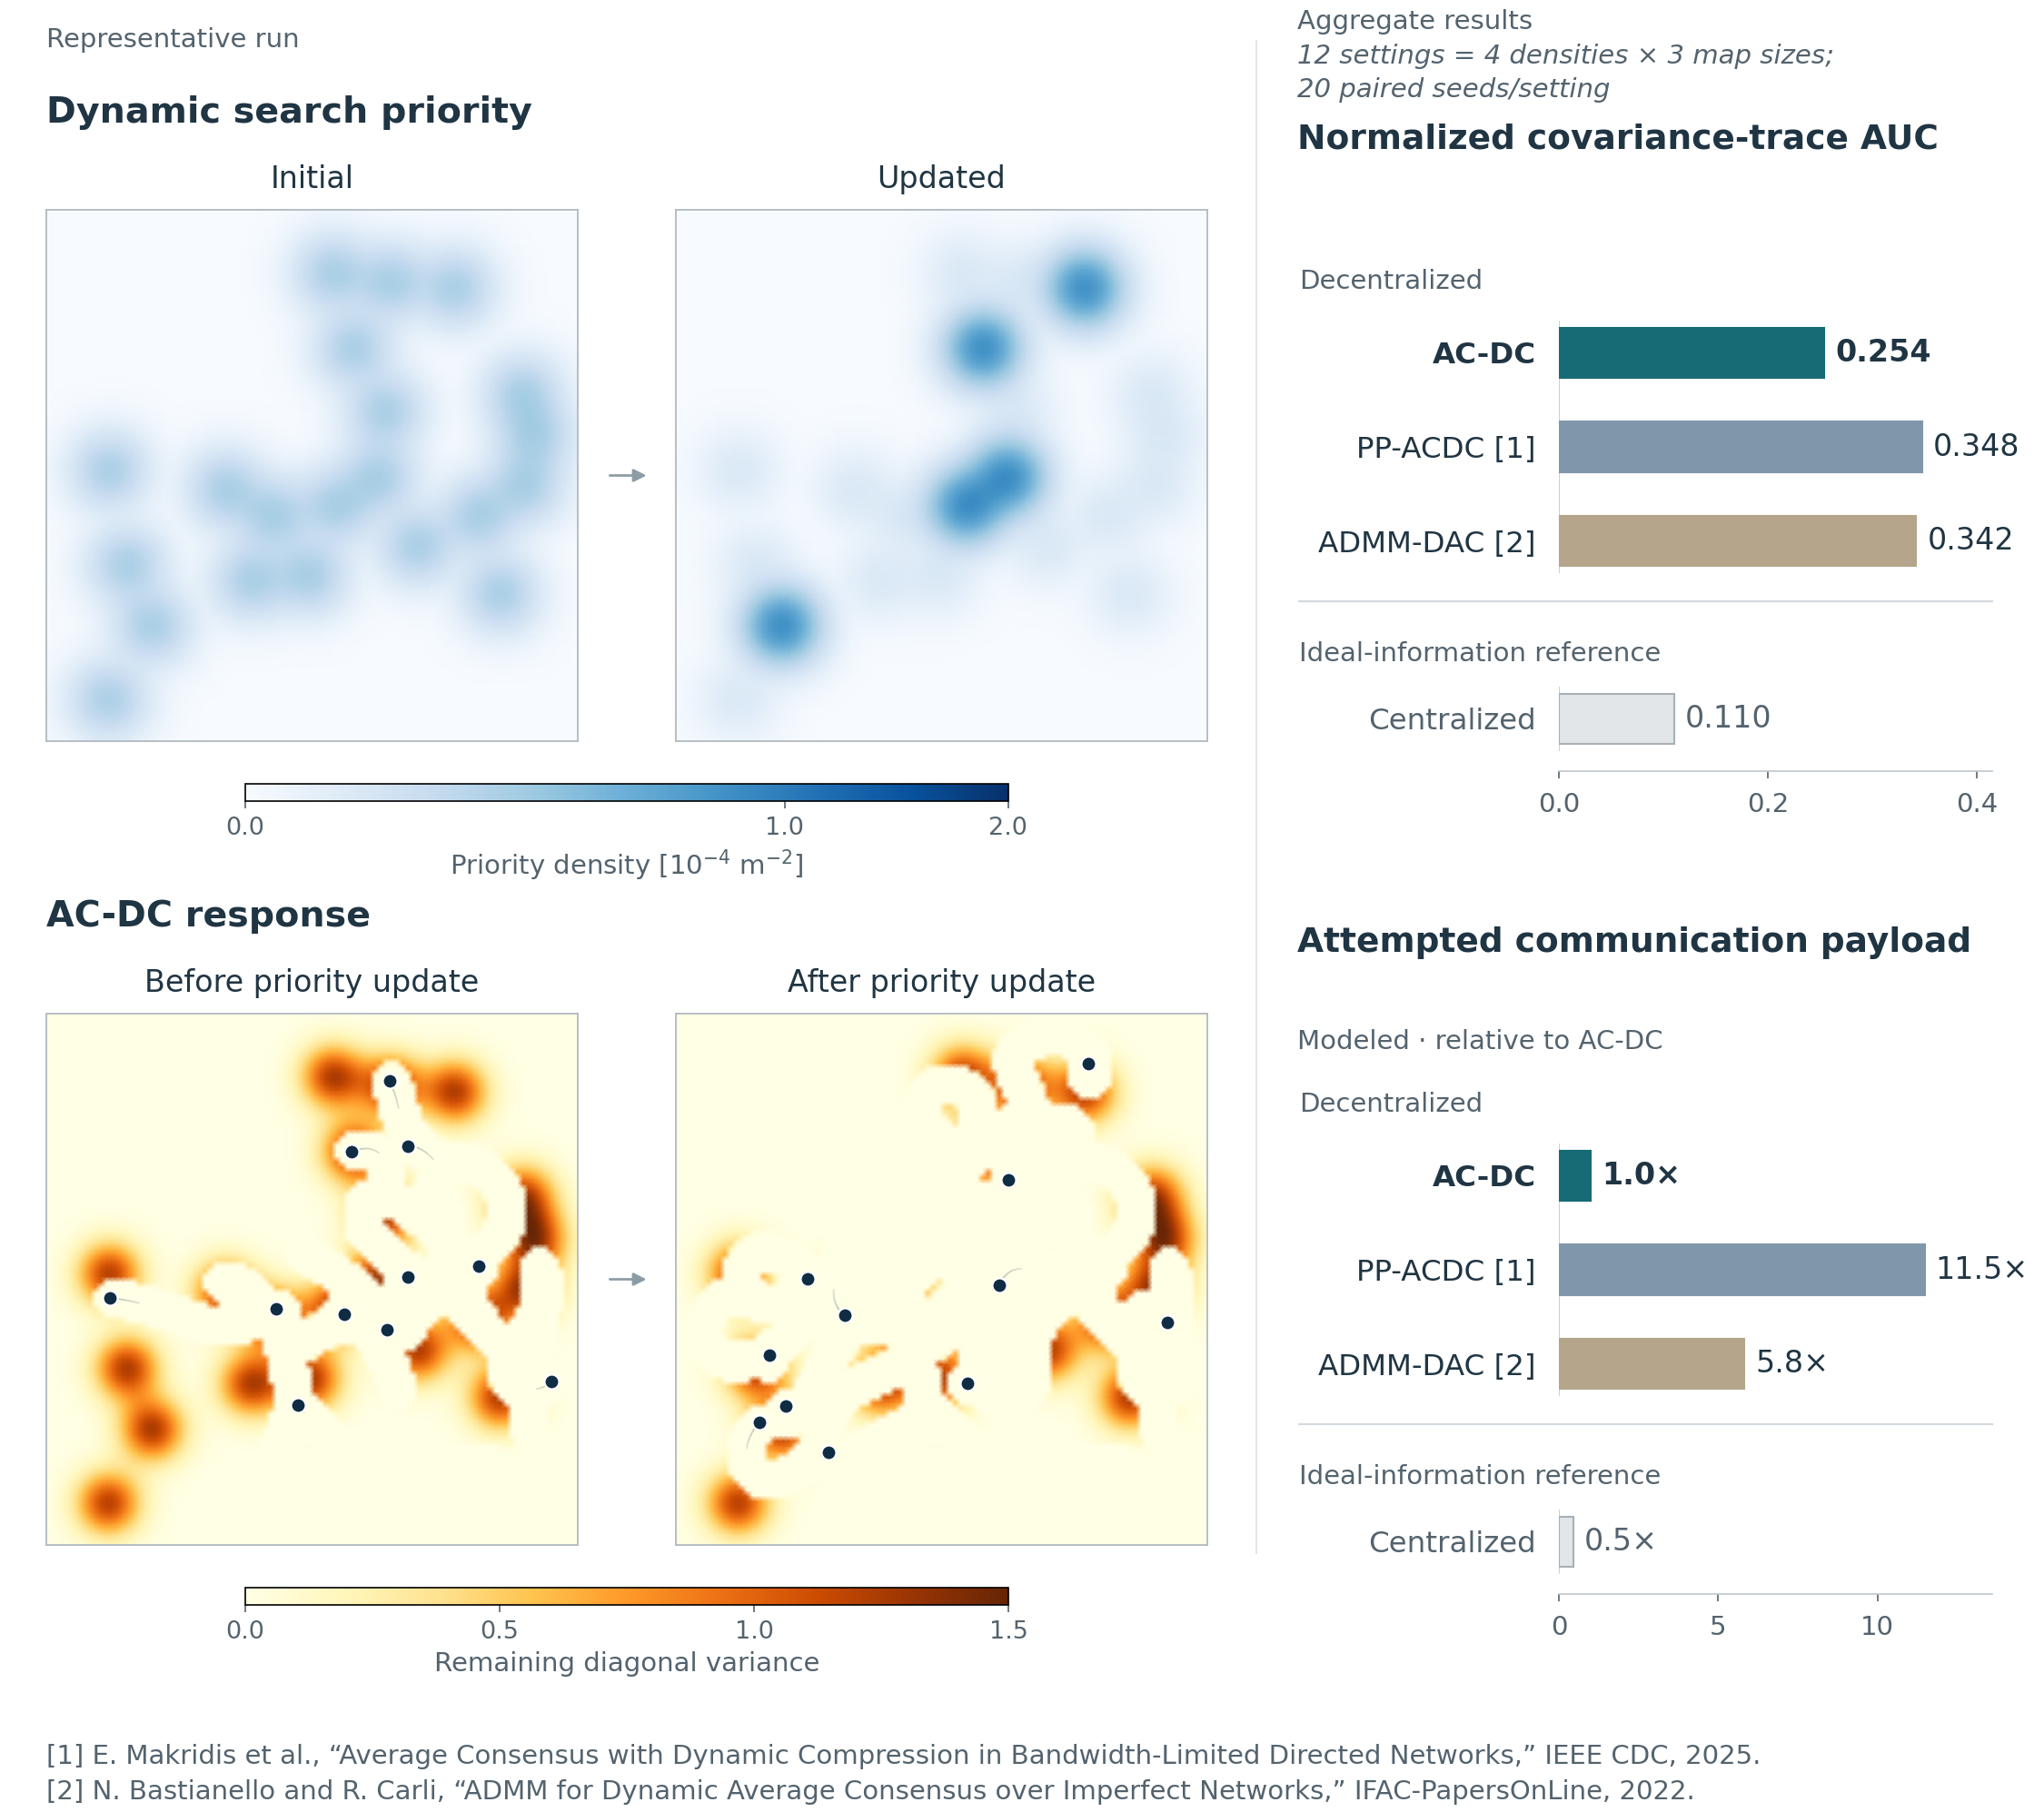
The mission priority changes at 100 s, so the regions that matter most also change during the run.
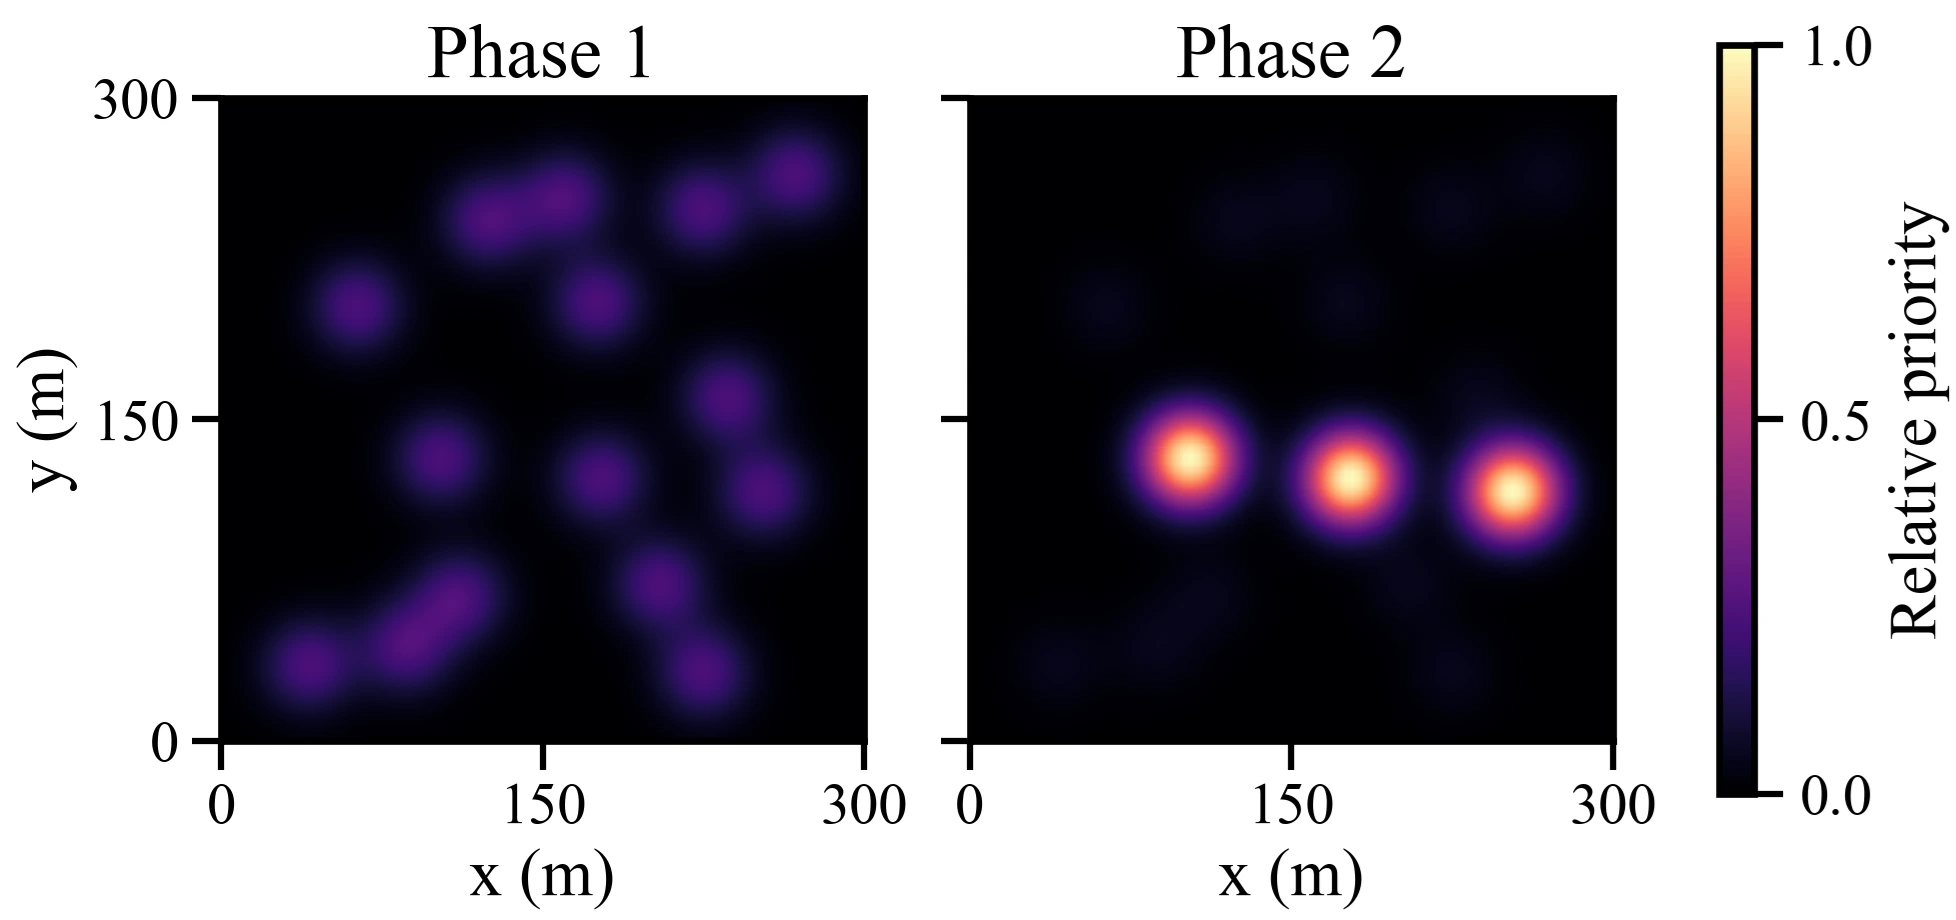
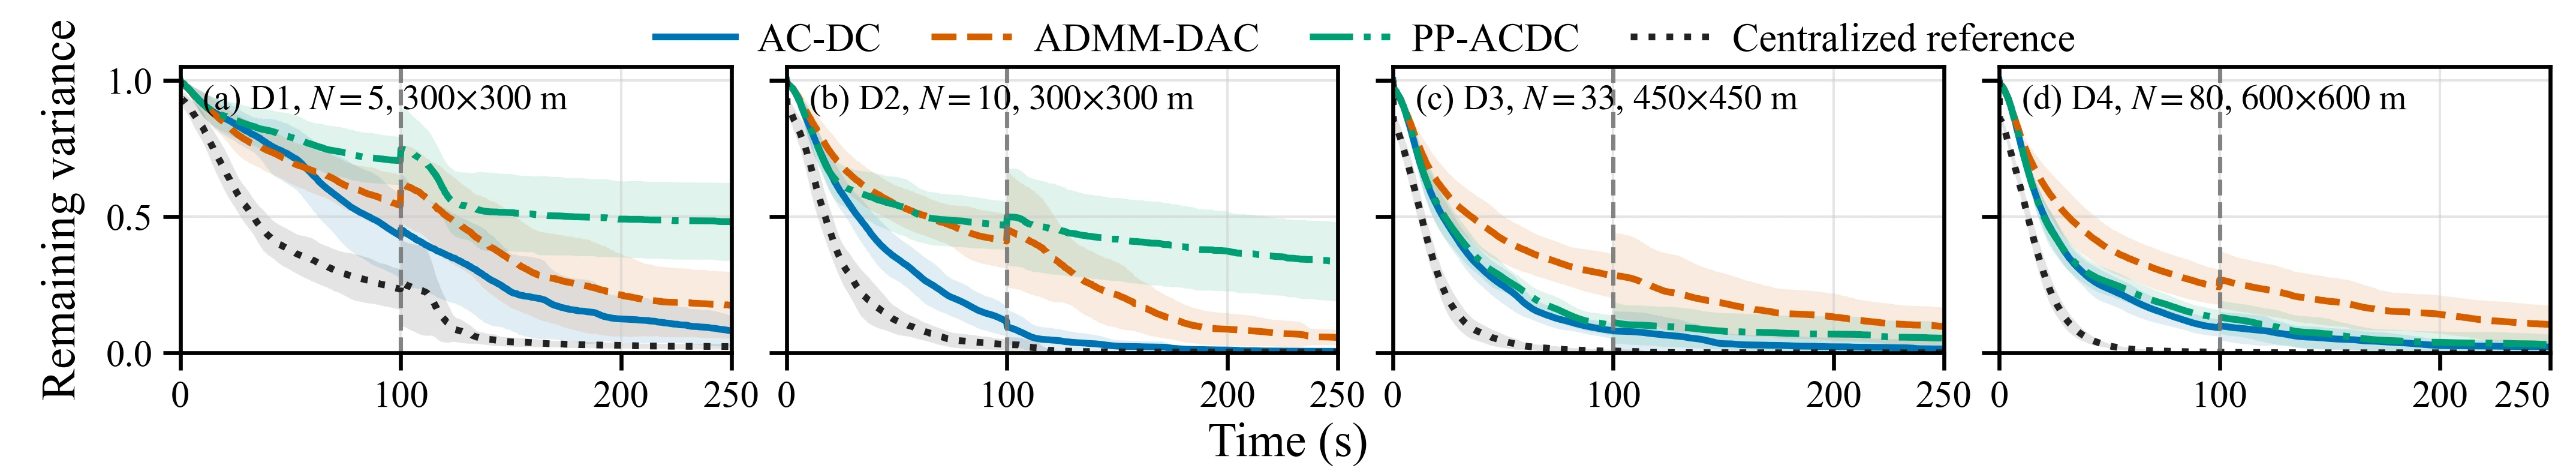
We evaluate closed-loop search using the normalized priority-weighted remaining covariance-trace ratio (W(t)). Lower values indicate less mission-relevant uncertainty. Each trajectory is summarized by the time-averaged area under this curve (AUC), so lower AUC is better.
The main study covers 12 map-size / density settings, with 20 paired trials per setting and teams up to 80 robots.
Results
Across all twelve settings, AC-DC had the lowest mean AUC and attempted modeled payload among the compared decentralized methods. The paired aggregate reductions were 29.5% versus ADMM-DAC and 24.5% versus PP-ACDC. Those baselines used 5.8× and 11.5× AC-DC’s modeled traffic, respectively.
Communication scaling
In the fixed 600 × 600 m scaling study with selected-block communication, AC-DC used 19.3 MB at 120 robots, compared with 19.2 MB for the ideal centralized reference.
This is a communication-scaling comparison, not a claim of centralized-level search performance. At the same team size, the corresponding AUCs were 0.129 for AC-DC and 0.041 for the ideal centralized reference, which operates outside the constrained robot mesh with exact team information.
Takeaway
AC-DC treats communication as a decision inside the autonomy stack. Rather than asking every robot to exchange every state whenever possible, each robot adapts What, When, and Who using information it can maintain locally.