Motivation
Control Barrier Functions provide a tractable safety layer, but their practical behavior depends strongly on the class-K parameters. Under input constraints, conservative parameters can preserve feasibility while slowing the robot down; aggressive parameters can improve nominal progress but become infeasible or unsafe near obstacles.
OA-CBF asks how those parameters can be adapted at runtime without treating one learned prediction as automatically trustworthy.
OA-CBF
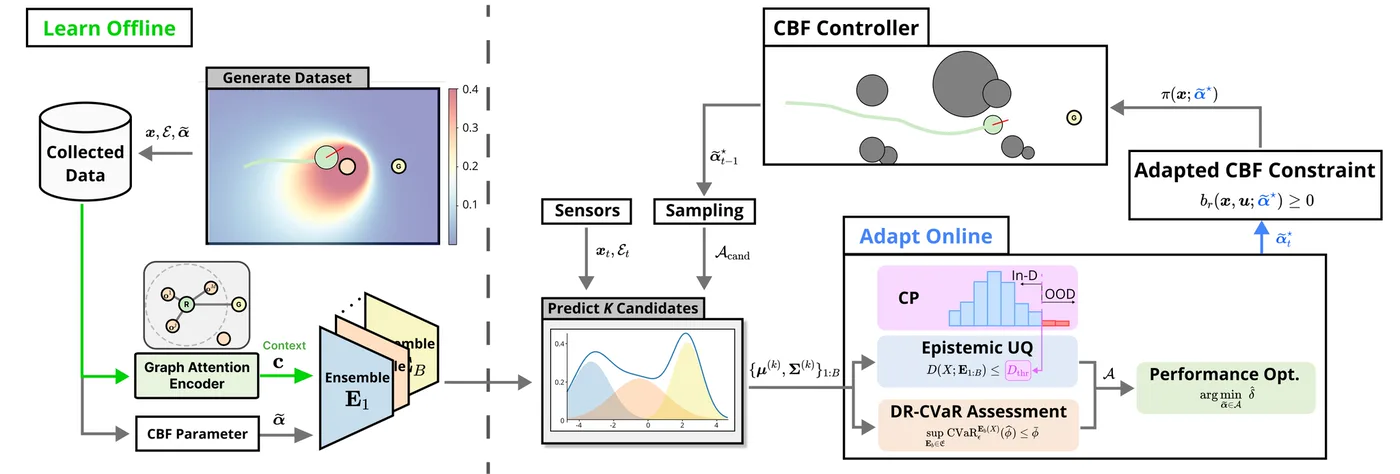
Sample candidate CBF parameters for the current robot state and environment.
A probabilistic ensemble evaluates each queried parameter using a graph-attention representation of the robot, goal, and obstacles.
Reject unreliable candidates using epistemic and aleatoric uncertainty and local finite-horizon validity.
Select the verified candidate with the best predicted task progress and update the CBF-based controller.
A key change from our ICRA 2025 work is the formulation around locally validated CBF parameters. Rather than only screening predicted performance and risk, OA-CBF evaluates candidate parameters over a finite prediction horizon and adapts the controller through repeatedly validated updates.
Why query candidates instead of predicting one parameter?
The learned model does not directly output a single “best” CBF parameter. It evaluates queried candidates. This makes uncertainty part of the decision process: candidates can be rejected when the model is not sufficiently confident or when the predicted safety behavior is not locally valid.
Captures uncertainty associated with the learned model and unfamiliar inputs.
Represents variability in the predicted outcome and is considered during candidate verification.
Among validated candidates, prefer the parameter predicted to make the best mission progress.
VTOL quadplane case study
We apply OA-CBF to a VTOL quadplane transition and landing scenario. Fixed low CBF parameters can produce a large altitude detour, while fixed high parameters can become infeasible and eventually collide.
OA-CBF adapts the parameters with the aircraft state. At high speed it keeps lower parameters, encouraging the elevator to pitch up and generate additional drag; as the aircraft slows, the parameters increase to improve performance.
Representative motion results
The official OA-CBF project page includes animated comparisons that show why online adaptation matters in the VTOL transition-and-landing case.
Fixed low CBF parameters remain feasible but produce a large altitude detour.
Fixed high CBF parameters become infeasible and eventually lead to collision.
OA-CBF adapts the CBF parameters with aircraft state to balance safety and task progress.
Quad3D results
The Quad3D benchmark shows OA-CBF on a fully three-dimensional quadrotor model. The unified view compares methods in the same environment, while the OA-CBF view highlights the online adaptation behavior.
Quad3D: unified view with compared methods.
Quad3D: OA-CBF with graph-attention environment encoding.
Dynamic Parabolic CBF results
The project also evaluates OA-CBF with a Dynamic Parabolic CBF (DPCBF) for a kinematic bicycle in dynamic-obstacle environments. This benchmark uses a relative-velocity-based safety condition, showing that the adaptation framework is not restricted to distance-based barriers.
Kinematic bicycle with DPCBF: unified view with compared methods.
Kinematic bicycle with DPCBF: OA-CBF with graph-attention environment encoding.
Relationship to our ICRA 2025 work
The ICRA 2025 Online Adaptive ICCBF project established uncertainty-aware online parameter adaptation under input constraints using a probabilistic ensemble plus JRD and distributionally robust CVaR verification. OA-CBF extends this research direction with a more general candidate-querying framework, local finite-horizon validation, graph-attention environment encoding, and additional robotic systems.
Status
This project is currently presented as a 2026 preprint. The project page intentionally does not list an archival journal venue until that publication status is public.